
PHYS-344 · Lesson 4 of 12 · 25 min
Lagrangian mechanics: generalized coordinates and constraints
Lesson 1 showed that Hamilton's principle reproduces Newton's law for a single particle in one dimension. This lesson builds the full machinery: Lagrange's equations for any number of generalized coordinates, a derivation from Newton's laws through d'Alembert's principle that shows exactly when they hold, and a recipe for applying them. We then use the recipe on two systems that are awkward with forces, a bead on a spinning hoop and a double pendulum, and check the results numerically.
Constraints and their classification
A constraint restricts the possible configurations or motions of a system. Constraints that can be written as equations among the coordinates and time, \(f(\mathbf r_1, \dots, \mathbf r_N, t) = 0\), are called holonomic. A pendulum rod of fixed length, a bead threaded on a wire, and two particles joined by a rigid bar are holonomic. Each such equation removes one degree of freedom, and with \(k\) of them a system of \(N\) particles has \(n = 3N - k\) generalized coordinates \(q_1, \dots, q_n\), in terms of which every position can be written as \(\mathbf r_i = \mathbf r_i(q_1, \dots, q_n, t)\).
Constraints that depend explicitly on time, such as a bead on a hoop that is being spun, are called rheonomic; those that do not are scleronomic. Constraints that restrict velocities in a way that cannot be integrated to a relation among coordinates, such as rolling without slipping on a plane, are nonholonomic; lesson 5 deals with them. Inequality constraints, such as a particle that must stay outside a sphere, are different again: they hold only while contact lasts, and the bead leaving a hemisphere in lesson 5 is an example.
Virtual displacements and d'Alembert's principle
Constraint forces, such as the tension in a pendulum rod or the normal force from a wire, are generally unknown until the motion is known. The key observation of analytical mechanics is that for ideal constraints these forces do no work in any displacement consistent with the constraints at a fixed instant. Such a displacement is called a virtual displacement \(\delta\mathbf r_i\): an imagined, instantaneous change of configuration that respects the constraints as they are at time \(t\). A frictionless wire pushes perpendicular to itself, and a virtual displacement along the wire is perpendicular to that push, so the work is zero. A rigid rod pulls equally and oppositely on its two ends, and any virtual displacement keeps the rod's length fixed, so the total work is zero.
Write Newton's law for particle \(i\) as \(m_i\ddot{\mathbf r}_i = \mathbf F_i + \mathbf C_i\), separating the applied forces \(\mathbf F_i\) (gravity, springs, electric forces) from the constraint forces \(\mathbf C_i\). Dot with \(\delta\mathbf r_i\) and sum. Since \(\sum_i \mathbf C_i\cdot\delta\mathbf r_i = 0\) for ideal constraints,
This is d'Alembert's principle, published by Jean le Rond d'Alembert in 1743. The constraint forces have vanished. If the \(\delta\mathbf r_i\) were independent we could set each bracket to zero, but they are not, because of the constraints. The cure is to express everything in terms of the independent generalized coordinates.
From d'Alembert to Lagrange
Since \(\mathbf r_i = \mathbf r_i(q, t)\), a virtual displacement (at fixed \(t\)) is \(\delta\mathbf r_i = \sum_j \frac{\partial\mathbf r_i}{\partial q_j}\delta q_j\), where now the \(\delta q_j\) are independent. The applied-force term becomes \(\sum_j Q_j\delta q_j\), with the generalized force
For the inertial term we need two identities. The velocity is \(\dot{\mathbf r}_i = \sum_j \frac{\partial\mathbf r_i}{\partial q_j}\dot q_j + \frac{\partial\mathbf r_i}{\partial t}\), so \(\frac{\partial\dot{\mathbf r}_i}{\partial\dot q_j} = \frac{\partial\mathbf r_i}{\partial q_j}\) (cancellation of dots). And \(\frac{d}{dt}\frac{\partial\mathbf r_i}{\partial q_j} = \frac{\partial\dot{\mathbf r}_i}{\partial q_j}\) (the order of differentiation can be swapped). Using both,
where \(T_i = \tfrac12 m_i\dot{\mathbf r}_i^2\). Summing over particles and using the independence of the \(\delta q_j\) gives one equation for each coordinate:
If the applied forces come from a potential \(V(q, t)\), then \(Q_j = -\partial V/\partial q_j\). Since \(V\) does not depend on the velocities, we can move it inside the first term and write \(L = T - V\):
These are Lagrange's equations, and they are exactly the Euler–Lagrange equations of the action. We have proved Hamilton's principle from Newton's laws for any system with ideal holonomic constraints and potential forces. When some forces are not conservative, such as friction, keep them on the right as \(Q_j\). Magnetic forces, which depend on velocity, can still be included in \(L\) through a velocity-dependent potential, as lesson 9 shows.
The recipe
In practice, solving a problem with Lagrange's equations follows the same steps every time. Choose generalized coordinates that build in the constraints. Write the position of each mass in Cartesian components in terms of those coordinates, differentiate to get the velocities, and assemble \(T = \sum\tfrac12 m_i v_i^2\). Write the potential energy \(V\). Form \(L = T - V\). For each coordinate compute \(\partial L/\partial\dot q_j\), differentiate it with respect to time, compute \(\partial L/\partial q_j\), and set the difference to zero. Finally, look for cyclic coordinates and for time independence, which give conserved quantities without further work.
The quantity \(p_j = \partial L/\partial\dot q_j\) is called the generalized or canonical momentum conjugate to \(q_j\). For a Cartesian coordinate it is the ordinary momentum; for an angle it is an angular momentum; for some other coordinates it has no simple name. Lagrange's equation says \(\dot p_j = \partial L/\partial q_j\), so if \(q_j\) is cyclic, \(p_j\) is conserved.
Example: a bead on a spinning hoop
A bead of mass \(m\) slides without friction on a circular hoop of radius \(R\). The hoop spins at a fixed angular velocity \(\omega\) about its vertical diameter, driven by a motor. Let \(\theta\) be the angle of the bead from the bottom of the hoop. The constraint is rheonomic: the hoop's orientation changes with time, but \(\theta\) alone fixes the bead's position at each instant.
The bead's distance from the axis is \(R\sin\theta\), and it moves with velocity \(R\dot\theta\) along the hoop and \(\omega R\sin\theta\) perpendicular to it. These are at right angles, so \(T = \tfrac12 m(R^2\dot\theta^2 + \omega^2R^2\sin^2\theta)\). The height above the bottom is \(R(1 - \cos\theta)\), so
Then \(\partial L/\partial\dot\theta = mR^2\dot\theta\) and \(\partial L/\partial\theta = mR^2\omega^2\sin\theta\cos\theta - mgR\sin\theta\), giving
Equilibria are where the right side vanishes: \(\theta = 0\) (bottom), \(\theta = \pi\) (top), and, if \(\omega^2 > g/R\), \(\cos\theta_0 = g/(R\omega^2)\). Linearize about each. About \(\theta = 0\), \(\ddot\theta \approx -(g/R - \omega^2)\theta\), stable only if \(\omega < \omega_c = \sqrt{g/R}\), with frequency \(\sqrt{g/R - \omega^2}\). About \(\theta_0\), write \(\theta = \theta_0 + \xi\); differentiating the right side at \(\theta_0\) gives \(\ddot\xi = -\omega^2\sin^2\theta_0\,\xi\), a stable oscillation at frequency \(\Omega = \omega\sin\theta_0\).
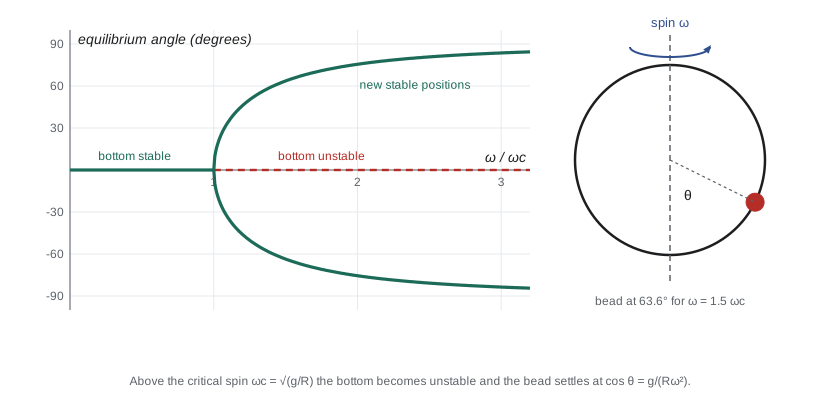
This is a pitchfork bifurcation: as the control parameter \(\omega\) passes \(\omega_c\), one stable equilibrium splits into two stable ones and an unstable one. The bead must choose a side, breaking the left–right symmetry of the hoop. Physically, when the hoop spins fast enough the centrifugal effect, which grows with distance from the axis, beats gravity's pull toward the bottom. The Lagrangian made this easy: we never needed the normal force of the hoop on the bead, which has two components and depends on the motion.
An important subtlety is that the energy \(T + V\) is not conserved here, because the motor does work on the hoop. Yet \(L\) has no explicit \(t\), so the Beltrami quantity \(h = \dot\theta\,\partial L/\partial\dot\theta - L = \tfrac12 mR^2(\dot\theta^2 - \omega^2\sin^2\theta) - mgR\cos\theta\) is conserved. It is not the energy: the term \(\tfrac12 mR^2\omega^2\sin^2\theta\) enters with a minus sign. This conserved quantity, called the energy function or Jacobi integral, equals the energy only when the coordinates are related to Cartesian ones without explicit time dependence.
Example: the double pendulum
Two equal masses \(m\) hang from equal massless rods of length \(\ell\), the second from the first, swinging in a vertical plane. With angles \(\theta_1\), \(\theta_2\) from the vertical, the first mass is at \((\ell\sin\theta_1, -\ell\cos\theta_1)\) and the second at \((\ell\sin\theta_1 + \ell\sin\theta_2, -\ell\cos\theta_1 - \ell\cos\theta_2)\). Squaring the velocities and using \(\cos\theta_1\cos\theta_2 + \sin\theta_1\sin\theta_2 = \cos(\theta_1 - \theta_2)\),
Lagrange's two equations are linear in \(\ddot\theta_1\) and \(\ddot\theta_2\), and solving them gives the expressions used in the program below. With forces this problem requires the tension in both rods and careful bookkeeping of accelerations of a point attached to a moving point; with the Lagrangian it takes half a page. PHYS-244 used the double pendulum as its example of chaos; here we check that our equations are right by testing energy conservation.
import math

def rk4(f, y, dt):
    k1 = f(y); k2 = f([a + dt / 2 * b for a, b in zip(y, k1)])
    k3 = f([a + dt / 2 * b for a, b in zip(y, k2)]); k4 = f([a + dt * b for a, b in zip(y, k3)])
    return [a + dt / 6 * (p + 2 * q + 2 * r + s) for a, p, q, r, s in zip(y, k1, k2, k3, k4)]

# 1. Bead on a hoop of radius R spinning at omega about its vertical diameter.
#    L = (m/2)(R^2 thdot^2 + R^2 omega^2 sin^2 th) + m g R cos th   (th = 0 at the bottom)
#    Lagrange: thddot = sin th (omega^2 cos th - g/R)
g, R = 9.81, 0.20
wc = math.sqrt(g / R)
print(f"critical spin rate sqrt(g/R) = {wc:.3f} rad/s")
for w in (0.8 * wc, 1.5 * wc, 2.5 * wc):
    if w > wc:
        th_eq = math.acos(g / (R * w * w)); Om = w * math.sin(th_eq)          # small-oscillation frequency
    else:
        th_eq = 0.0; Om = math.sqrt(g / R - w * w)
    f = lambda y: [y[1], math.sin(y[0]) * (w * w * math.cos(y[0]) - g / R)]
    y = [th_eq + 0.01, 0.0]; t = 0.0; dt = 1e-4; crossings = []; prev = y[0] - th_eq
    while len(crossings) < 3:
        y = rk4(f, y, dt); t += dt
        cur = y[0] - th_eq
        if prev < 0 <= cur: crossings.append(t)
        prev = cur
    T_num = crossings[2] - crossings[1]
    print(f"omega = {w / wc:.1f} x critical: equilibrium at {math.degrees(th_eq):5.1f} deg, "
          f"period {T_num:.4f} s (formula {2 * math.pi / Om:.4f} s)")

# 2. Double pendulum (equal masses m, equal lengths l) from its Lagrangian; energy must stay constant.
l = 1.0
def dp(y):
    t1, t2, w1, w2 = y; d = t1 - t2
    den = 3 - math.cos(2 * d)
    a1 = (-3 * g * math.sin(t1) - g * math.sin(t1 - 2 * t2) - 2 * math.sin(d) * (w2 * w2 * l + w1 * w1 * l * math.cos(d))) / (l * den)
    a2 = (2 * math.sin(d) * (2 * w1 * w1 * l + 2 * g * math.cos(t1) + w2 * w2 * l * math.cos(d))) / (l * den)
    return [w1, w2, a1, a2]
def energy(y):   # per unit mass
    t1, t2, w1, w2 = y
    T = 0.5 * l * l * (2 * w1 * w1 + w2 * w2 + 2 * w1 * w2 * math.cos(t1 - t2))
    V = -g * l * (2 * math.cos(t1) + math.cos(t2))
    return T + V
y = [math.radians(120), math.radians(-20), 0.0, 0.0]; E0 = energy(y)
dt = 1e-3
for step in range(1, 20001):
    y = rk4(dp, y, dt)
    if step % 5000 == 0:
print(f"t = {step * dt:4.1f} s: theta1 = {math.degrees(y[0]):8.2f} deg, relative energy error {abs(energy(y) - E0) / abs(E0):.1e}")critical spin rate sqrt(g/R) = 7.004 rad/s omega = 0.8 x critical: equilibrium at 0.0 deg, period 1.4952 s (formula 1.4952 s) omega = 1.5 x critical: equilibrium at 63.6 deg, period 0.6677 s (formula 0.6677 s) omega = 2.5 x critical: equilibrium at 80.8 deg, period 0.3635 s (formula 0.3635 s) t = 5.0 s: theta1 = 96.33 deg, relative energy error 1.0e-08 t = 10.0 s: theta1 = -85.93 deg, relative energy error 1.4e-08 t = 15.0 s: theta1 = -23.97 deg, relative energy error 1.6e-08 t = 20.0 s: theta1 = 32.57 deg, relative energy error 3.4e-08
For a hoop of radius 0.20 m the critical rate is \(\omega_c = 7.004\ \mathrm{rad/s}\), about 67 revolutions per minute. Below it, the bead oscillates about the bottom with period \(2\pi/\sqrt{g/R - \omega^2}\); above it, about \(\theta_0 = \arccos(g/R\omega^2)\), which is 63.6 degrees at \(1.5\omega_c\) and 80.8 degrees at \(2.5\omega_c\), with period \(2\pi/(\omega\sin\theta_0)\). The periods measured by integrating the full nonlinear equation agree with the linearized formulas to four figures. For the double pendulum released from 120 and \(-20\) degrees, the motion is wild, but the energy stays constant to a few parts in \(10^8\) over 20 s. An error in the equations of motion would show up immediately as energy drift, which makes energy a useful check on any derivation.
Worked problem
A pendulum hanging from a sliding support
A block of mass \(M\) slides without friction on a horizontal rail. From it hangs a pendulum of mass \(m\) and length \(\ell\). Find the Lagrangian, identify a conserved quantity, and find the frequency of small oscillations.
Show solution
- Coordinates: the block's position \(x\) and the pendulum angle \(\theta\). The bob is at \((x + \ell\sin\theta, -\ell\cos\theta)\).
- \(T = \tfrac12 M\dot x^2 + \tfrac12 m\big[(\dot x + \ell\cos\theta\,\dot\theta)^2 + \ell^2\sin^2\theta\,\dot\theta^2\big] = \tfrac12(M + m)\dot x^2 + m\ell\cos\theta\,\dot x\dot\theta + \tfrac12 m\ell^2\dot\theta^2\); \(V = -mg\ell\cos\theta\).
- \(x\) is cyclic, so \(p_x = (M + m)\dot x + m\ell\cos\theta\,\dot\theta\) is conserved: the total horizontal momentum.
- For small \(\theta\), set \(p_x = 0\): \(\dot x = -\frac{m\ell}{M + m}\dot\theta\). The \(\theta\) equation, linearized, is \(m\ell\ddot x + m\ell^2\ddot\theta + mg\ell\theta = 0\).
- Substituting, \(m\ell^2\big(1 - \frac{m}{M + m}\big)\ddot\theta + mg\ell\theta = 0\), so \(\omega^2 = \frac{g}{\ell}\frac{M + m}{M}\).
Answer: \(\omega = \sqrt{(g/\ell)(1 + m/M)}\). A light support (small \(M\)) moves back and forth with the bob, and the pendulum swings faster than \(\sqrt{g/\ell}\) because the two masses oscillate about their common center of mass.
Common mistakes
MistakeWriting the kinetic energy in generalized coordinates without going through Cartesian positions.
InsteadWrite each position in Cartesian components first, differentiate, and square; cross terms such as \(\dot\theta_1\dot\theta_2\cos(\theta_1 - \theta_2)\) are easy to miss otherwise.
MistakeIncluding constraint forces in the potential energy.
InsteadIdeal constraint forces do no virtual work and do not appear in \(L\) at all; the constraints are built into the choice of coordinates.
MistakeAssuming \(T + V\) is conserved whenever \(L\) has no explicit time dependence.
InsteadThe conserved quantity is \(\sum\dot q\,\partial L/\partial\dot q - L\), which equals \(T + V\) only when the coordinate transformation is time-independent.
MistakeConfusing virtual and real displacements.
InsteadA virtual displacement is taken at fixed time; for a moving constraint, real displacements can include motion of the constraint itself, on which constraint forces do work.
MistakeForgetting that \(\partial L/\partial\dot q\) must be differentiated with respect to time along the motion.
InsteadEvery \(q\) and \(\dot q\) inside it varies, so the chain rule brings in all the second derivatives.
Summary and key terms
- Holonomic constraints are equations among coordinates; each removes a degree of freedom and can be built into generalized coordinates.
- Ideal constraint forces do no work in virtual displacements; d'Alembert's principle \(\sum(\mathbf F_i - m_i\ddot{\mathbf r}_i)\cdot\delta\mathbf r_i = 0\) eliminates them.
- Expressed in generalized coordinates this gives \(\frac{d}{dt}\partial T/\partial\dot q_j - \partial T/\partial q_j = Q_j\), and with potential forces Lagrange's equations \(\frac{d}{dt}\partial L/\partial\dot q_j - \partial L/\partial q_j = 0\).
- The canonical momentum \(p_j = \partial L/\partial\dot q_j\) is conserved for a cyclic coordinate, and \(h = \sum\dot q_j p_j - L\) is conserved when \(L\) has no explicit time dependence.
- A bead on a hoop spinning faster than \(\sqrt{g/R}\) leaves the bottom in a pitchfork bifurcation; energy is not conserved there, but the Jacobi integral is.
- holonomic constraint
- A constraint expressible as an equation among coordinates and time.
- rheonomic constraint
- A constraint that depends explicitly on time, such as a moving wire.
- virtual displacement
- An infinitesimal change of configuration consistent with the constraints at a fixed instant.
- d'Alembert's principle
- The sum of (applied force minus mass times acceleration) dotted with virtual displacements vanishes.
- generalized force
- The coefficient Q_j of δq_j in the virtual work of the applied forces.
- Jacobi integral
- The conserved quantity Σ q̇ ∂L/∂q̇ − L for a Lagrangian without explicit time dependence.
Practice problems
Work each problem on paper first, then reveal the answer to check.
Find the equation of motion of a particle sliding on a frictionless wire bent into the parabola \(y = x^2/2a\) in a vertical plane.
Show answer
\(L = \tfrac12 m\dot x^2(1 + x^2/a^2) - mgx^2/2a\); Lagrange gives \(m(1 + x^2/a^2)\ddot x + m x\dot x^2/a^2 + mgx/a = 0\).
For the bead on the hoop with \(R = 0.30\ \mathrm m\), find \(\omega_c\) and the equilibrium angle at \(\omega = 10\ \mathrm{rad/s}\).
Show answer
\(\omega_c = \sqrt{9.81/0.30} = 5.72\ \mathrm{rad/s}\); \(\cos\theta_0 = 9.81/(0.30\cdot100) = 0.327\), so \(\theta_0 = 70.9^\circ\).
What is the small-oscillation frequency about that equilibrium?
Show answer
\(\Omega = \omega\sin\theta_0 = 10 \times 0.945 = 9.45\ \mathrm{rad/s}\).
An Atwood machine has masses \(m_1\), \(m_2\) on a light pulley. Use \(x\), the drop of \(m_1\), as the coordinate and find \(\ddot x\).
Show answer
\(L = \tfrac12(m_1 + m_2)\dot x^2 + m_1gx - m_2gx\), so \(\ddot x = g(m_1 - m_2)/(m_1 + m_2)\).
Compute the generalized force for \(\theta\) when a horizontal force \(F\) pushes on the bob of a pendulum.
Show answer
\(Q_\theta = F\,\partial x/\partial\theta = F\ell\cos\theta\), a torque.
Why is \(T + V\) not conserved for the bead on the spinning hoop?
Show answer
The motor must apply a torque to keep \(\omega\) fixed as the bead moves, so it does work on the system.
Lesson quiz · 5 questions
Score 60% or more to complete this lesson.
Create a free account to save your progress, take quizzes and earn a certificate.