
ROB-460 · Lesson 1 of 12 · 33 min
What makes field robotics hard
Field robotics is the branch of robotics concerned with machines that work outdoors or in other unstructured, unprepared places: farms, mines, forests, oceans, the Arctic, disaster sites and other planets. A factory robot works in a cell built around it, with fixed lighting, known parts and fences. A field robot has to cope with the world as it is. This lesson sets out what makes that hard, how engineers think about environment, reliability and support, and how the rest of the course is organized. It assumes the localization and mapping methods of ROB-340, the planning methods of ROB-350 and the estimation methods of ROB-310, and builds on them rather than repeating them.
From the cell to the field
Industrial robots succeed because the environment is engineered to suit them. Parts arrive in fixtures, the floor is flat, nothing moves unexpectedly and the robot can repeat the same motion millions of times. Field robots invert almost every one of those assumptions. The ground is soft, wet, frozen or covered in rock; lighting changes from noon glare to darkness; rain, snow, fog and dust degrade sensors; vegetation grows and blows in the wind; animals, people and other machines appear without warning; and communication links come and go. The task itself is often less repetitive, because every field, ore face or ship hull is different.
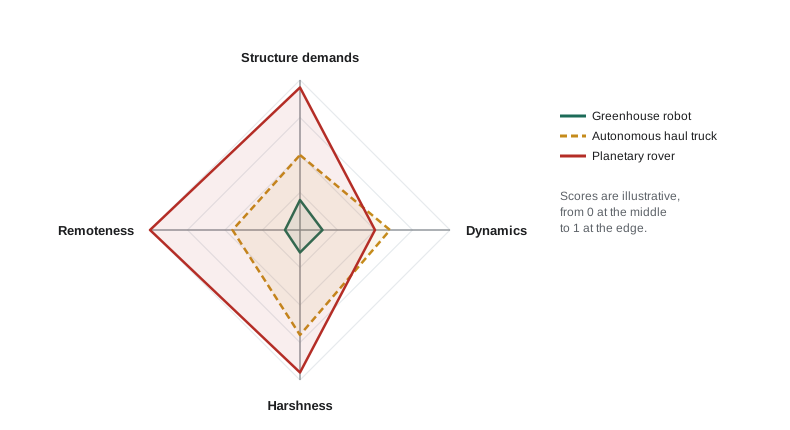
Researchers often describe field environments along a few axes. Structure is how much of the environment was built for the robot or follows known rules. Dynamics is how much the environment changes while the robot works, from a slowly growing crop to a breaking wave. Harshness covers temperature, moisture, dust, pressure, radiation and vibration. Remoteness covers distance from human help and from reliable communication. A robot mowing a golf course is low on most axes; a robot inspecting a pipeline under Arctic sea ice is high on all four.
| Axis | Low end | High end | Design consequence |
|---|---|---|---|
| Structure | Orchard with trellised rows | Collapsed building after an earthquake | More reliance on general perception and planning, fewer prior maps |
| Dynamics | Pipeline right-of-way | Surf zone or active mine face | Faster replanning, conservative speed, prediction of moving objects |
| Harshness | Greenhouse | Oil sands mine at minus 40 degrees, or the lunar surface | Sealing, thermal design, derated batteries, radiation tolerance |
| Remoteness | Robot in sight of its operator | Mars rover 20 light-minutes away | Onboard autonomy, fault protection, delay-tolerant operations |
Lessons from field robotics history
Several landmark efforts shaped how the field approaches these problems. NASA's Sojourner rover in 1997, the Spirit and Opportunity rovers from 2004 and later Curiosity and Perseverance showed that careful engineering and conservative autonomy could keep machines working for years beyond their design lives on another planet; Opportunity, planned for 90 sols, operated for more than 14 years. The DARPA Grand Challenge of 2005, won by Stanford's Stanley, showed that a vehicle could drive 212 km of desert route without a driver by combining lidar, cameras and probabilistic methods. The DARPA Subterranean Challenge, which concluded in 2021, pushed teams of ground robots and drones to explore tunnels, caves and urban underground spaces with little or no communication; the systems competition was won by Team CSIRO Data61 from Australia. Commercially, autonomous haul trucks have operated in Australian iron ore mines since the late 2000s, and Imperial Oil reported in 2023 that its entire fleet of 81 haul trucks at the Kearl oil sands mine in Alberta was autonomous.
A common thread runs through these stories. Success rarely came from a single clever algorithm. It came from integrating robust sensing, conservative behavior, good fault detection, extensive field testing and an operations team that understood the robot's limits. Field robotics is as much systems engineering as it is algorithm design.
Environmental protection and hardening
Before any autonomy runs, the robot must survive its environment. Ingress protection is usually specified with the IP code of IEC 60529, in which the first digit rates protection against solids and dust and the second against water. An IP65 enclosure is dust-tight and protected against water jets; IP67 is dust-tight and survives temporary immersion; IP68 covers continuous immersion under conditions agreed with the manufacturer. Field robots usually need at least IP65 for outdoor work and IP67 or better where they may wade or be washed down. Connectors, cable glands, vents and seals around shafts are the usual failure points, not the enclosure walls.
Temperature is the second major stress. Electronics, lubricants, seals and especially batteries have limited operating ranges. Lithium-ion cells lose available capacity and power in the cold because their internal resistance rises, and most cannot be charged safely below about 0 degrees without heating. Many field robots therefore carry battery heaters, insulated enclosures or thermal management loops, and plan missions with derated energy budgets in winter. Heat is just as serious in deserts and mines, where solar loading and engine heat push electronics toward their limits. Vibration and shock from rough terrain loosen connectors, crack solder joints and fatigue brackets; designs use strain relief, locking connectors, potting and vibration testing to standards such as IEC 60068-2.
| Stress | Typical effects | Common countermeasures |
|---|---|---|
| Dust and sand | Abrasion, clogged fans and filters, coated lenses | IP6X enclosures, sealed bearings, lens wipers or air knives |
| Water, mud and snow | Short circuits, corrosion, frozen joints | IP67 or better, conformal coating, drainage, heated seals |
| Cold | Battery capacity and power loss, brittle plastics, stiff grease | Battery heaters, insulation, low-temperature lubricants |
| Heat and sun | Thermal shutdown, faster battery aging | Shading, light-colored housings, heat sinks, derating |
| Vibration and shock | Loose connectors, cracked solder, sensor misalignment | Locking connectors, isolation mounts, potting, recalibration checks |
Worked problem
Choosing an ingress rating
An orchard robot is washed with a low-pressure hose at the end of each day and may drive through puddles up to 20 cm deep. Its electronics box sits 50 cm above the ground. Which IP rating should the box and its connectors meet?
Show solution
- Daily hosing means protection against water jets is needed: second digit at least 5.
- Puddles reach 20 cm, below the box, but splashing and spray during driving are likely; immersion of the box itself is not expected.
- Orchard dust and pollen call for a dust-tight first digit of 6.
- Connectors and glands must meet the same rating when mated; unmated connectors need caps.
Answer: IP65 as a minimum for the box and mated connectors; IP66 or IP67 gives margin for high-pressure washing or deeper water.
Worked problem
Cold-weather energy budget
A survey robot has a 2.0 kWh battery and uses 250 W on average at 20 degrees. At minus 20 degrees, the manufacturer's curve shows 70 percent of rated capacity is usable, and heaters add 40 W. Estimate the run time at each temperature, keeping a 20 percent reserve.
Show solution
- Usable energy at 20 degrees with reserve: \( 2.0 \times 0.8 = 1.6 \) kWh.
- Run time at 20 degrees: \( 1600 / 250 = 6.4 \) h.
- Usable energy at minus 20 degrees: \( 2.0 \times 0.70 \times 0.8 = 1.12 \) kWh.
- Power with heaters: \( 250 + 40 = 290 \) W, so run time \( 1120 / 290 \approx 3.9 \) h.
Answer: About 6.4 h in mild weather but only about 3.9 h at minus 20 degrees, a 40 percent reduction. The figures are illustrative; real derating curves come from the cell maker.
# Run time versus temperature for a field robot battery (illustrative derating curve)
import numpy as np
temps = np.array([-30, -20, -10, 0, 10, 20, 30])
usable = np.array([0.55, 0.70, 0.80, 0.88, 0.95, 1.00, 1.00])  # fraction of rated capacity
heater_w = np.where(temps < 0, 40 + 2 * (0 - temps), 0)       # heater power grows as it gets colder
capacity_wh, load_w, reserve = 2000, 250, 0.20
for t, u, h in zip(temps, usable, heater_w):
    hours = capacity_wh * u * (1 - reserve) / (load_w + h)
print(f"{t:4d} C usable {u:4.0%} heater {h:3.0f} W run time {hours:4.1f} h")-30 C usable 55% heater 100 W run time 2.5 h -20 C usable 70% heater 80 W run time 3.4 h -10 C usable 80% heater 60 W run time 4.1 h 0 C usable 88% heater 0 W run time 5.6 h 10 C usable 95% heater 0 W run time 6.1 h 20 C usable 100% heater 0 W run time 6.4 h 30 C usable 100% heater 0 W run time 6.4 h
The table shows why winter missions need different plans from summer ones. The loss is not only stored energy: cold cells also deliver less peak power, which matters for robots that need bursts of current to climb slopes or to drive through deep snow.
Reliability, availability and redundancy
A field robot that fails far from help is expensive. Recovering a stuck rover in a muddy field costs labor and lost time; recovering a failed underwater vehicle may cost a ship-day worth tens of thousands of dollars; a failure on Mars cannot be repaired at all. Reliability engineering gives a vocabulary for these concerns. Mean time between failures (MTBF) is the average operating time between failures that stop the mission. Mean time to repair (MTTR) is the average time to restore the robot to service, including travel and diagnosis. Inherent availability is the fraction of time the robot is ready to work:
Field operations usually have a long MTTR because the robot is remote. That makes improvements in MTTR, such as modular swappable parts, remote diagnostics and spare robots, as valuable as improvements in MTBF. Where failures are random and the failure rate \( \lambda = 1/\mathrm{MTBF} \) is roughly constant, the probability that a robot completes a mission of length \( t \) without failure is \( R(t) = e^{-\lambda t} \).
Worked problem
Availability of a field robot fleet member
An agricultural robot has an MTBF of 120 operating hours. When it fails in the field, a technician must drive out, diagnose and repair it, taking 6 hours on average. What is its inherent availability, and what happens if a swap-in spare module cuts MTTR to 1.5 hours?
Show solution
- \( A = 120 / (120 + 6) = 0.952 \), about 95.2 percent.
- With MTTR of 1.5 h: \( A = 120 / 121.5 = 0.988 \), about 98.8 percent.
- Downtime falls from about 4.8 percent to 1.2 percent of operating time.
Answer: About 95 percent availability, rising to about 99 percent with faster repair; cutting MTTR by a factor of four removed three-quarters of the downtime without changing reliability.
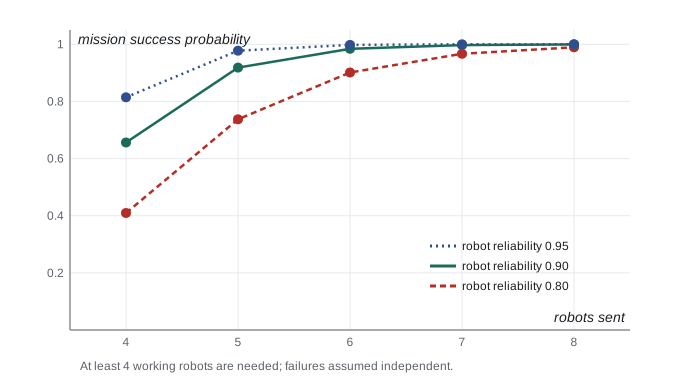
Multi-robot systems change the reliability picture, which is one reason the second half of this course studies them. If a mission needs at least \( k \) of \( n \) robots to succeed, and each robot independently survives with probability \( p \), the mission succeeds with probability
# k-out-of-n mission reliability: how many robots must we send?
from math import comb
def k_of_n(k, n, p):
    return sum(comb(n, i) * p**i * (1 - p)**(n - i) for i in range(k, n + 1))
p = 0.90          # each robot completes the mission with probability 0.90
k = 4             # the survey needs at least 4 working robots
for n in range(4, 9):
print(f"send {n} robots: mission success {k_of_n(k, n, p):.4f}")send 4 robots: mission success 0.6561 send 5 robots: mission success 0.9185 send 6 robots: mission success 0.9841 send 7 robots: mission success 0.9973 send 8 robots: mission success 0.9996
Sending exactly the four robots needed gives only about a two-in-three chance of success, because any single failure ends the mission. Adding one spare raises success to over 90 percent, and two spares push it above 98 percent. The assumption of independent failures is optimistic: robots of the same design share software bugs, batteries from the same batch and the same weather, so common cause failures reduce the benefit, just as they do in the safety calculations of ROB-450.
Autonomy, supervision and the human team
Few field robots are fully autonomous in the sense of operating for long periods with no human involvement. Most work under supervised autonomy: the robot drives, plans and handles routine events itself, while a human supervisor monitors one or many robots, approves risky actions and intervenes when the robot is stuck or uncertain. ROB-430 lesson 6 described teleoperation and shared autonomy in detail; field operations add the problems of intermittent communication and of one supervisor responsible for a fleet. Lesson 11 returns to these issues. The human team also includes field technicians who maintain the robots, operations planners who decide where and when they work, and customers whose workflows change around the robots.
Field robotics programs often fail not because the robot cannot do the task in a demonstration, but because it cannot do it every day, in all weather, for a cost the customer can accept. A useful discipline is to measure mean distance or time between interventions, the fraction of the task completed without help, and the cost of each intervention. Those numbers, gathered over seasons rather than days, are what decide whether a field robot becomes a product.
| Metric | What it measures | Example target |
|---|---|---|
| Mean time between interventions | How often a human must help | More than one shift for a farm robot |
| Task completion without help | Share of the planned work done autonomously | Above 95 percent of rows weeded |
| Intervention cost | Labor and travel per intervention | Under 15 minutes of remote help on average |
| Availability | Ready-to-work fraction of scheduled time | Above 95 percent in season |
| Cost per unit of work | Total cost divided by hectares, metric tons or kilometers | Competitive with the manual or conventional method |
How this course is organized
Lessons 2 and 3 cover the two foundations every ground robot needs outdoors: getting across rough terrain and knowing where it is when GNSS and lidar are degraded. Lessons 4 to 8 survey application domains: agriculture; mining, construction and energy; marine and underwater work; aerial field operations; and space. Each domain lesson highlights the physics and economics that shape its robots. Lessons 9 and 10 turn to teams of robots, first with explicit task allocation and then with swarms and distributed control. Lesson 11 covers communication, levels of autonomy and supervision in the field, and lesson 12 combines everything in the design of a multi-robot field mission. Regulation of mobile robots, automated vehicles and drones was covered in ROB-450 lessons 6 and 7, and automated vehicles in depth in ROB-420; this course refers to those lessons rather than repeating them.
Common mistakes
MistakeTreating a field robot as a factory robot that has been put outdoors.
InsteadDesign for unstructured, changing and harsh environments from the start: sealing, thermal design, robust perception and recovery behaviors.
MistakeQuoting battery run time from a warm-weather test.
InsteadPlan with derated capacity and heater loads at the coldest expected temperature, plus a reserve.
MistakeImproving MTBF while ignoring repair time.
InsteadRemote field work has long MTTR; modular parts, diagnostics and spares often raise availability more cheaply.
MistakeSending exactly the number of robots a mission needs.
InsteadUse k-out-of-n reasoning to choose spares, and remember that common cause failures reduce the benefit.
MistakeJudging success from a short demonstration.
InsteadMeasure interventions, availability and cost per unit of work over full seasons and all weather.
Summary and key terms
- Field robots work in unstructured, dynamic, harsh and remote environments that were not built for them.
- Four axes, structure, dynamics, harshness and remoteness, help characterize an application and its design consequences.
- Landmark programs from planetary rovers to the DARPA challenges and autonomous haulage show that success comes from systems engineering and field testing.
- IP ratings, thermal design and vibration hardening are prerequisites; cold sharply reduces battery capacity and power.
- Availability depends on both MTBF and MTTR, and remote work makes MTTR large.
- k-out-of-n reliability shows how spares improve mission success, limited by common cause failures.
- Supervised autonomy and operational metrics such as interventions per shift decide whether field robots become products.
- Field robotics
- Robotics in unstructured, outdoor or otherwise unprepared environments such as farms, mines, oceans and planets.
- Unstructured environment
- An environment not engineered around the robot, with unknown or changing geometry and appearance.
- IP code
- The IEC 60529 rating of an enclosure's protection against solids (first digit) and water (second digit).
- Derating
- Using a component below its nominal rating, such as planning with reduced battery capacity in the cold.
- MTBF
- Mean time between failures: average operating time between mission-stopping failures.
- MTTR
- Mean time to repair: average time to restore a failed system, including travel and diagnosis.
- Inherent availability
- MTBF divided by the sum of MTBF and MTTR.
- k-out-of-n system
- A system that works if at least k of its n components work.
- Supervised autonomy
- Operation in which the robot acts autonomously while a human monitors and intervenes when needed.
- Mean time between interventions
- Average operating time between occasions when a human must help the robot.
Practice problems
Work each problem on paper first, then reveal the answer to check.
Place a robotic lawn mower and an under-ice survey vehicle on the four environmental axes and explain the differences.
Show answer
The mower is low on structure demands (lawns are fairly predictable), low on dynamics, low on harshness and low on remoteness. The under-ice vehicle faces little structure, moving ice and currents, extreme cold and pressure, and no direct communication, so it is high on all four.
Why are connectors and seals more likely than enclosure walls to let water in?
Show answer
They are joints and moving interfaces that depend on correct assembly, gaskets and mating; walls are continuous material.
A robot uses 300 W, has a 3 kWh battery and keeps a 25 percent reserve. At minus 15 degrees, 75 percent of capacity is usable and heaters draw 50 W. Find run time.
Show answer
\( 3000 \times 0.75 \times 0.75 / 350 \approx 4.8 \) h.
Calculate availability for MTBF 200 h and MTTR 8 h.
Show answer
\( 200/208 \approx 0.962 \).
What is the probability that a robot with MTBF 100 h completes a 10 h mission, assuming a constant failure rate?
Show answer
\( e^{-10/100} \approx 0.905 \).
A mission needs 2 of 3 robots, each with reliability 0.9. Compute the success probability.
Show answer
\( 3(0.9^2)(0.1) + 0.9^3 = 0.243 + 0.729 = 0.972 \).
Give two reasons why robot failures in a fleet may not be independent.
Show answer
Shared software bugs and design flaws; shared environment such as a storm; components from the same batch; shared communication infrastructure.
What did the DARPA Subterranean Challenge emphasize that earlier challenges did not?
Show answer
Exploration underground with degraded or absent communication, using heterogeneous teams of ground robots and drones.
Name three operational metrics a farm customer would care about.
Show answer
Mean time between interventions, task completion without help, availability, cost per hectare.
Why might an autonomous haul truck fleet still need a large human team?
Show answer
Supervision in a control room, maintenance, mine planning, managing interactions with staffed equipment, and handling exceptions.
Lesson quiz · 5 questions
Score 60% or more to complete this lesson.
Create a free account to save your progress, take quizzes and earn a certificate.