
ROB-460 · Lesson 9 of 12 · 31 min
Multi-robot coordination and task allocation
Many field missions are too large, too urgent or too risky for one robot. A fleet of weeding robots covers a farm in the spraying window; several AUVs map a seabed faster; a team of ground robots and drones explores a mine after an accident. Multiple robots can work in parallel, specialize, and back each other up, but they must decide who does what, avoid getting in each other's way and share what they learn. This lesson covers the structure of multi-robot task allocation problems, optimal assignment with the Hungarian algorithm, market-based and auction methods, routing several robots through many tasks, coordinating paths and sharing maps. Lesson 10 turns to swarms, where coordination emerges from simple local rules rather than explicit allocation.
Why teams, and what makes them hard
Teams offer speed through parallelism, robustness through redundancy (lesson 1's k-out-of-n reasoning), and capability through heterogeneity, for example a drone that scouts and a ground robot that carries a heavy sensor. They also introduce new problems. Allocation decides which robot performs which task and in what order. Coordination prevents conflicts, such as two robots trying to use the same narrow passage or charging station. Communication is limited in range, bandwidth and reliability, so robots may have different and outdated information. Scalability matters because methods that work for three robots may be impractical for fifty. Finally, the team's objective must be chosen carefully: minimizing the total distance travelled by all robots and minimizing the time until the last task is done (the makespan) can lead to very different plans.
Gerkey and Matarić proposed a widely used taxonomy of multi-robot task allocation (MRTA) along three axes. Single-task robots (ST) can do one task at a time, while multi-task robots (MT) can do several at once. Single-robot tasks (SR) need one robot, while multi-robot tasks (MR) need several working together, such as carrying a large object. Instantaneous assignment (IA) allocates tasks using only current information, while time-extended assignment (TA) plans a schedule of future tasks for each robot. The simplest class, ST-SR-IA, is the classical assignment problem and can be solved optimally in polynomial time; most other classes are NP-hard and need heuristics.
| Class | Meaning | Example | Solution approach |
|---|---|---|---|
| ST-SR-IA | Each robot does one task; each task needs one robot; assign now | Send each of five drones to one of five search sectors | Hungarian algorithm (optimal) |
| ST-SR-TA | Each robot does a sequence of single-robot tasks | Weeding robots each visiting many field patches | Routing heuristics, auctions, mixed-integer programming |
| ST-MR-IA | Some tasks need a coalition of robots | Two robots together lifting a heavy object | Coalition formation, set partitioning heuristics |
| MT-SR-IA | A robot can serve several tasks at once | A drone relaying communications while imaging | Problem-specific formulations |
Optimal assignment: the Hungarian algorithm
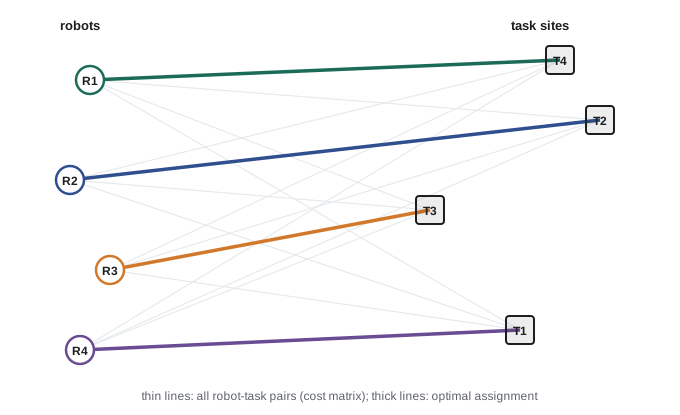
When there are \( n \) robots and \( n \) tasks and each robot can take exactly one task, the problem is to choose a one-to-one assignment minimizing the total cost, for example travel distance or time. With a cost matrix \( C \) where \( C_{ij} \) is the cost for robot \( i \) to perform task \( j \), we choose binary variables \( x_{ij} \) to
The Hungarian algorithm, developed by Kuhn in 1955 from earlier work by Hungarian mathematicians, solves this exactly in \( O(n^3) \) time. It works by subtracting row and column minimums to create zeros, then finding the maximum set of independent zeros and adjusting the matrix until a complete assignment of zeros exists. Rectangular problems with more tasks than robots, or the reverse, are handled by padding with dummy rows or columns. Library implementations such as linear_sum_assignment in SciPy make this practical for hundreds of robots.
Worked problem
A three-robot assignment by hand
Three robots must each go to one of three sites. Travel times in minutes are: robot A to sites 1, 2, 3: 9, 2, 7; robot B: 6, 4, 3; robot C: 5, 8, 1. Find the assignment minimizing total time.
Show solution
- Subtract each row minimum: A becomes 7, 0, 5; B becomes 3, 1, 0; C becomes 4, 7, 0.
- Subtract each column minimum (3, 0, 0): A becomes 4, 0, 5; B becomes 0, 1, 0; C becomes 1, 7, 0.
- Independent zeros: A to site 2, B to site 1, C to site 3.
- Total: \( 2 + 6 + 1 = 9 \) minutes.
Answer: A to site 2, B to site 1 and C to site 3, for 9 minutes in total; a greedy choice starting with C to site 3 then A to site 2 gives the same here, but greedy methods can be far worse in general.
# Optimal versus greedy assignment of robots to tasks
import numpy as np
from scipy.optimize import linear_sum_assignment
rng = np.random.default_rng(9)
def compare(n, trials=200):
    gaps = []
    for _ in range(trials):
        robots, tasks = rng.uniform(0, 1000, (n, 2)), rng.uniform(0, 1000, (n, 2))
        C = np.linalg.norm(robots[:, None, :] - tasks[None, :, :], axis=2)
        r, c = linear_sum_assignment(C)
        opt = C[r, c].sum()
        free_r, free_t, greedy = set(range(n)), set(range(n)), 0.0
        while free_r:                    # repeatedly take the cheapest remaining pair
            i, j = min(((i, j) for i in free_r for j in free_t), key=lambda p: C[p])
            greedy += C[i, j]; free_r.remove(i); free_t.remove(j)
        gaps.append(greedy / opt - 1)
    return np.mean(gaps), np.max(gaps)
for n in (5, 10, 20, 40):
    mean_gap, worst = compare(n)
print(f"{n:3d} robots: greedy is {mean_gap:5.1%} worse on average, {worst:5.1%} in the worst trial")5 robots: greedy is 7.8% worse on average, 47.8% in the worst trial 10 robots: greedy is 11.2% worse on average, 40.3% in the worst trial 20 robots: greedy is 15.2% worse on average, 37.2% in the worst trial 40 robots: greedy is 18.3% worse on average, 36.0% in the worst trial
Greedy assignment is simple and often reasonable, but in this simulation it is 8 to 18 per cent worse than optimal on average, and up to nearly 50 per cent worse in unlucky cases, because an early cheap choice can force expensive later ones. When the cost matrix can be computed centrally, there is little reason not to use the optimal algorithm.
Market-based allocation and auctions
Centralized optimization needs a reliable link from every robot to a planner that knows all costs. In the field, links fail, robots discover new tasks, and conditions change, so decentralized methods are attractive. Market-based approaches treat tasks as goods and robots as bidders. In a single-item auction, an auctioneer, which may be any robot, announces a task; each robot computes its cost to add the task to its plan and bids; the lowest bidder wins. Sequential single-item auctions allocate tasks one at a time, each robot bidding its marginal cost given the tasks it already holds, which naturally handles time-extended problems. Combinatorial auctions let robots bid on bundles of tasks, capturing synergies such as two tasks being close together, at higher computational cost.
Auction methods are robust and simple: if a robot fails, its tasks can be re-auctioned, and new tasks can be auctioned as they appear. They are not generally optimal, but for some objectives their solutions come with performance guarantees relative to optimal. The consensus-based bundle algorithm (CBBA) combines bundle construction with a consensus phase in which robots exchange winning bids with neighbours until they agree, so it works without a central auctioneer and converges to a conflict-free assignment with guaranteed performance under some conditions. Practical systems often use auctions for initial allocation and repair, and local optimization to improve each robot's route.
# Sequential single-item auction for time-extended allocation (each robot builds a route)
import numpy as np
rng = np.random.default_rng(12)
depots = np.array([[0, 0], [1000, 0], [500, 900]], float)       # three robots start here
tasks = rng.uniform(0, 1000, (15, 2))
def route_cost(start, pts):
    pos, total = start, 0.0
    for p in pts:
        total += np.linalg.norm(p - pos); pos = p
    return total
def best_insertion(start, route, t):
    best = (np.inf, 0)
    for k in range(len(route) + 1):
        new = route[:k] + [t] + route[k:]
        best = min(best, (route_cost(start, [tasks[i] for i in new]) -
                          route_cost(start, [tasks[i] for i in route]), k))
    return best
def auction(objective):
    routes = [[] for _ in depots]
    for t in range(len(tasks)):                 # announce tasks one at a time
        bids = []
        for r, start in enumerate(depots):
            inc, k = best_insertion(start, routes[r], t)
            current = route_cost(start, [tasks[i] for i in routes[r]])
            bid = inc if objective == "total" else current + inc     # minmax: bid resulting route length
            bids.append((bid, r, k))
        bid, r, k = min(bids)
        routes[r].insert(k, t)
    lengths = [route_cost(s, [tasks[i] for i in rt]) for s, rt in zip(depots, routes)]
    return routes, lengths
for objective in ("total", "minmax"):
    routes, lengths = auction(objective)
    print(f"{objective:6s} bids: tasks per robot {[len(r) for r in routes]}, route lengths "
f"{[round(x) for x in lengths]} m, total {sum(lengths):.0f} m, makespan {max(lengths):.0f} m")total bids: tasks per robot [8, 0, 7], route lengths [1845, 0, 1387] m, total 3231 m, makespan 1845 m minmax bids: tasks per robot [4, 4, 7], route lengths [1086, 951, 1387] m, total 3424 m, makespan 1387 m
The choice of bidding rule changes the result. Bidding marginal cost tends to minimize total distance but may load well-placed robots with most of the work, and here it leaves the second robot idle; bidding the resulting route length balances the work and shortens the makespan, usually at the cost of more total distance. Which is better depends on the mission: total distance matters for energy and wear, while makespan matters when a weather window or a search for survivors sets a deadline.
Routing teams through many tasks
Time-extended allocation for many tasks resembles the multiple travelling salesman problem (mTSP) and vehicle routing problems from operations research. Each robot starts at a depot, visits a subset of tasks and may return to recharge; constraints can include battery capacity, time windows, task precedence and robot capabilities. Exact solutions with mixed-integer programming are feasible for small problems; field systems typically use heuristics such as insertion, savings algorithms and local search (two-opt and moves of tasks between robots), or metaheuristics such as large neighbourhood search, with solvers re-run as conditions change. Energy constraints are especially important for field robots: a drone fleet surveying power lines must plan battery swaps, and an agricultural fleet must schedule returns to refill and recharge.
Worked problem
Total distance versus makespan
Two robots start at the same depot. Four tasks lie 100 m, 110 m, 500 m and 520 m away along a single straight road in the same direction. Plan A sends robot 1 to all four tasks in order and robot 2 nowhere; plan B sends robot 1 to the two near tasks and robot 2 to the two far tasks; plan C alternates, robot 1 taking the tasks at 100 m and 500 m and robot 2 those at 110 m and 520 m. Compare total distance and makespan, measured as distance, ignoring returns.
Show solution
- Plan A: robot 1 drives to 520 m, total 520 m; robot 2 drives 0 m. Total 520 m, makespan 520 m.
- Plan B: robot 1 drives 110 m; robot 2 drives 520 m. Total 630 m, makespan 520 m.
- Plan C: robot 1 takes 100 and 500 m, robot 2 takes 110 and 520 m: total 1,020 m, makespan 520 m.
- Here every plan has the same makespan because one robot must reach 520 m; plan A minimizes total distance.
Answer: Plan A has the lowest total distance with no makespan penalty, showing that splitting work is not automatically better; with tasks spread in different directions, balancing would shorten the makespan.
Coordinating paths and shared resources
Robots that each follow good individual plans may still collide, block narrow passages or queue at a single charging station. Multi-agent path finding (MAPF) computes collision-free paths for many agents on a graph. Prioritized planning plans robots one at a time, treating earlier robots' paths as moving obstacles; it is fast but can fail when a low-priority robot is boxed in. Conflict-based search finds optimal solutions by planning individually, detecting conflicts and branching on constraints that resolve them, and its bounded-suboptimal variants scale to hundreds of agents. In open fields, coordination is often simpler: robots are given separate areas or lanes, and traffic rules at headlands, gates and charging stations prevent conflicts. ROB-350 covered single-robot planning; MAPF builds on the same graph search ideas.
| Coordination method | How it works | Strengths | Weaknesses |
|---|---|---|---|
| Spatial partitioning | Each robot gets its own area or lanes | Simple, little communication | Unbalanced work if areas differ; poor for shared resources |
| Prioritized planning | Plan robots in order, avoiding earlier paths | Fast, easy to implement | Incomplete; low-priority robots can be blocked |
| Conflict-based search | Branch on constraints that resolve detected conflicts | Optimal or bounded-suboptimal | Can be slow with many dense conflicts |
| Traffic rules and reservations | Reserve passages, gates and chargers in time windows | Works with simple robots | Requires reliable communication or infrastructure |
Sharing information: maps and beliefs
A team is more than the sum of its robots only if they share what they learn. Multi-robot SLAM merges maps from several robots, which requires finding the relative transformation between their maps from shared observations or rendezvous; ROB-340 introduced the graph-based formulations that extend naturally to inter-robot loop closures. Bandwidth limits mean robots often exchange compressed submaps, keyframe descriptors or object-level summaries rather than raw scans. Robots must also handle inconsistent or outdated information about task status: two robots may both believe a task is free and travel to it. Systems use acknowledgements, task locks, timeouts and periodic re-synchronization, and they plan for robots to reconnect after hours out of range, as lesson 11 discusses.
The DARPA Subterranean Challenge provided a demanding test. Teams deployed several ground robots and drones into unknown underground environments, with a single human supervisor and communication available only near the entrance or through radios dropped by the robots as they advanced. Successful teams combined autonomous exploration with frontier-based task allocation, map merging when robots came back into contact, and a supervisor who could reassign robots. Their experience shows that multi-robot coordination in the field is as much about resilient information sharing as about optimal allocation.
Common mistakes
MistakeOptimizing total distance when the mission has a deadline.
InsteadChoose the objective deliberately; minimize makespan or include time windows when finishing early matters.
MistakeUsing greedy assignment when an optimal solver is easy to run.
InsteadFor one-to-one assignment, use the Hungarian algorithm; it is fast and exact.
MistakeAssuming all robots share the same, current information.
InsteadPlan for delayed and inconsistent knowledge with acknowledgements, locks, timeouts and resynchronization.
MistakePlanning each robot's path independently in tight spaces.
InsteadUse prioritized planning, conflict-based search, partitioning or reservations to prevent collisions and deadlock.
MistakeIgnoring energy and refill constraints in routing.
InsteadInclude battery capacity, charging and refill trips in allocation and routing.
Summary and key terms
- Robot teams offer parallelism, redundancy and heterogeneity but require allocation, coordination and communication.
- The Gerkey and Matarić taxonomy classifies MRTA problems by single or multi-task robots, single or multi-robot tasks and instantaneous or time-extended assignment.
- One-to-one assignment is solved optimally by the Hungarian algorithm in polynomial time; greedy methods can be noticeably worse.
- Auctions and consensus-based methods allocate tasks without a central planner and support repair when robots fail.
- Bidding rules and objectives such as total distance or makespan change the resulting plans.
- Routing several robots through many tasks is an mTSP or vehicle routing problem solved with heuristics and local search.
- Path coordination and information sharing, including map merging, are essential for teams in real field conditions.
- Multi-robot task allocation
- The problem of deciding which robots perform which tasks, and when.
- Makespan
- The time until the last task in a plan is completed.
- Assignment problem
- Choosing a one-to-one matching of agents to tasks minimizing total cost.
- Hungarian algorithm
- An exact polynomial-time method for the assignment problem.
- Single-item auction
- An allocation method in which robots bid for one task at a time and the best bid wins.
- Combinatorial auction
- An auction in which bidders bid on bundles of tasks.
- CBBA
- Consensus-based bundle algorithm, a decentralized auction method with a consensus phase.
- Multiple travelling salesman problem
- Finding routes for several salesmen that together visit all cities at minimum cost.
- Multi-agent path finding
- Computing collision-free paths for many agents moving on a shared graph.
- Map merging
- Combining maps built by different robots into one consistent map.
Practice problems
Work each problem on paper first, then reveal the answer to check.
Classify sending each of four AUVs to survey one of four separate areas in the MRTA taxonomy.
Show answer
ST-SR-IA: single-task robots, single-robot tasks, instantaneous assignment.
Solve the assignment for costs A: 4, 1; B: 2, 3 (rows robots, columns tasks).
Show answer
A to task 2 and B to task 1, total 3.
Why can greedy assignment perform badly?
Show answer
An early cheap choice can leave only expensive options for the remaining robots.
What is the computational complexity of the Hungarian algorithm?
Show answer
\( O(n^3) \) for n robots and n tasks.
How do auctions help when a robot fails during a mission?
Show answer
Its remaining tasks can be re-auctioned to the other robots without replanning from scratch.
Explain the difference between bidding marginal cost and bidding resulting route length.
Show answer
Marginal cost bids minimize added distance, favouring low total distance; route length bids favour balanced loads and lower makespan.
Give two constraints that make field robot routing harder than a basic mTSP.
Show answer
Battery capacity and recharging; time windows; robot capabilities; task precedence.
What weakness does prioritized planning have?
Show answer
It is incomplete: a low-priority robot may be unable to find a path around earlier robots' paths even if a joint solution exists.
Why do robots exchange compressed submaps rather than raw scans?
Show answer
Bandwidth is limited, especially in field communication networks.
What lessons for multi-robot systems came from the DARPA Subterranean Challenge?
Show answer
Resilient information sharing, map merging on reconnection, frontier-based allocation and a supervisor able to reassign robots are as important as optimal allocation.
Lesson quiz · 5 questions
Score 60% or more to complete this lesson.
Create a free account to save your progress, take quizzes and earn a certificate.