
ROB-460 · Lesson 4 of 12 · 34 min
Agricultural robotics
Agriculture was one of the first industries to adopt GNSS guidance at scale, and it is now one of the most active markets for field robots. Farms face shortages of skilled seasonal labour, pressure to cut herbicide and fertilizer use, concern about soil compaction from ever heavier machines, and narrow weather windows in which work must be done. This lesson surveys autonomous tractors and platforms, robots for weeding, spraying, harvesting and livestock, the coverage planning that underlies field operations, and the economics that decide whether robots replace, assist or simply change the shape of farm machinery. Product details are given as reported at the time of writing (October 2026) and change quickly.
From guidance to autonomy
Since the early 2000s, RTK auto-steer has let tractors follow straight or curved lines with a few centimetres of error, with the operator handling turns, implement control and safety. The next steps were automated headland turns, implement control linked to maps and machine-to-machine coordination, such as a combine harvester controlling the grain cart tractor that drives alongside it. Full autonomy removes the operator from the cab, which requires perception to detect people, animals and obstacles, a safety concept for the field, remote supervision and procedures for exceptions.
Several approaches coexist. Retrofit kits add cameras, computing and drive-by-wire interfaces to existing large tractors. Deere demonstrated a driverless 8R tractor for tillage in 2022 and at CES 2025 announced a second-generation perception kit with 16 stereo cameras for 8R and 9R tractors and tillage, plus kits for its 5ML orchard tractors and orchard sprayers using cameras and lidar, with wider availability planned for 2026. Purpose-built platforms take a different path. DOT, developed by DOT Technology in Regina, Saskatchewan, was a driverless U-shaped power unit that implements such as seeders and sprayers slide into; Raven Industries took control of the company in 2019 and rebranded it OMNiPower in 2021, and Raven was itself acquired by CNH. Raven's OMNiDrive kit, originally AutoCart, lets a combine operator command a driverless grain cart tractor. Other companies build smaller electric or diesel robots designed to work in fleets.
| Approach | Examples (as reported) | Advantages | Challenges |
|---|---|---|---|
| Retrofit autonomy kit on a large tractor | Deere 8R and 9R kits; aftermarket kits for grain carts | Uses existing fleet and implements; high work rate | Heavy machine near people; perception must cover a large vehicle |
| Purpose-built driverless platform | OMNiPower (originally DOT); various European platforms | Designed for autonomy and implement swapping | New equipment purchase; dealer support |
| Fleets of small robots | Research and commercial weeding and seeding robots | Less compaction, redundancy, lower risk per unit | Lower work rate per robot; more units to supervise and maintain |
| Cooperative automation | Combine controlling an autonomous grain cart | One operator supervises the pair; incremental adoption | Tight coordination and communication between machines |
Safety of highly automated agricultural machines is addressed by ISO 18497, which sets requirements for the design of such machines and their obstacle protection systems; designers should use the current edition. In practice, autonomous farm machines operate in fields with controlled access, stop for detected obstacles, and are monitored remotely by an operator who can see camera feeds and intervene. Regulation of public-road travel, drones and mobile robots was covered in ROB-450; on the farm, occupational health and safety law and the manufacturer's safety case are the main controls.
Coverage planning for field operations
Most field operations, from tillage to spraying, require covering an area with an implement of fixed working width. The standard pattern is boustrophedon coverage, named after the back-and-forth way an ox ploughs: parallel passes across the field, connected by turns in headlands at each end. ROB-350 treated motion planning in general; here the questions are practical. How long will the job take? How much area is overlapped or missed? How should the passes be oriented to reduce turns? The answers depend on implement width \( w \), overlap fraction, speed, turning time and field shape.
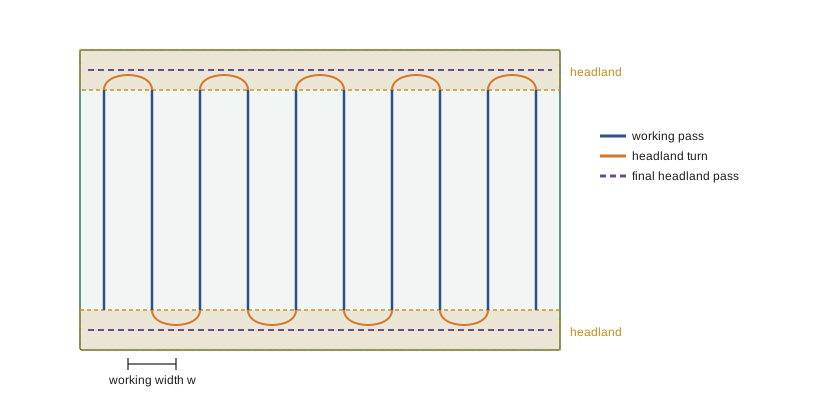
For a rectangular field of length \( L \) along the passes and width \( W \) across them, the number of passes is about \( N = \lceil W / (w(1 - o)) \rceil \) for overlap fraction \( o \). The working time is the pass length divided by speed times the number of passes, and the non-productive time is the number of turns times the time per turn, plus time for refilling, unloading or recharging. Field efficiency is the ratio of productive time to total time. Orienting passes along the longest side of the field minimizes the number of turns; irregular fields are split into cells that are each covered in their best orientation.
# Coverage time and field efficiency for a boustrophedon pattern
import math
def coverage(L, W, width, overlap, speed_kmh, turn_s, refill_every_ha=None, refill_min=0):
    passes = math.ceil(W / (width * (1 - overlap)))
    work_h = passes * L / (speed_kmh * 1000)
    turn_h = (passes - 1) * turn_s / 3600
    area_ha = L * W / 10000
    refill_h = 0 if refill_every_ha is None else math.floor(area_ha / refill_every_ha) * refill_min / 60
    total = work_h + turn_h + refill_h
    return passes, total, work_h / total, area_ha / total
field = dict(L=800, W=400)   # m
cases = {"large sprayer 36 m":   dict(width=36, overlap=0.02, speed_kmh=16, turn_s=40, refill_every_ha=40, refill_min=20),
         "small robot 3 m":      dict(width=3, overlap=0.05, speed_kmh=6, turn_s=25, refill_every_ha=4, refill_min=10),
         "passes along short side": dict(width=3, overlap=0.05, speed_kmh=6, turn_s=25, refill_every_ha=4, refill_min=10)}
for name, c in cases.items():
    L, W = (field["L"], field["W"]) if "short" not in name else (field["W"], field["L"])
    n, t, eff, rate = coverage(L, W, **c)
print(f"{name:24s} passes {n:4d} total {t:5.1f} h field efficiency {eff:4.0%} {rate:5.2f} ha/h")large sprayer 36 m passes 12 total 0.7 h field efficiency 83% 44.31 ha/h small robot 3 m passes 141 total 21.1 h field efficiency 89% 1.52 ha/h passes along short side passes 281 total 22.0 h field efficiency 85% 1.45 ha/h
The large sprayer covers the 32 ha field in under an hour of field time, while a single small robot needs about 21 hours. Running passes along the short side doubles the number of turns and lowers efficiency further. This is why small-robot concepts depend on fleets working in parallel and on operating many more hours per day, including at night, and why they suit tasks such as weeding, where precision and frequent passes matter more than raw work rate.
Worked problem
How many small robots replace one sprayer?
The sprayer covers about 44 ha per hour in the field above, but travel between fields, mixing and refilling cut its average to about 25 ha per hour over a 10-hour spraying day. A small robot averages about 1.5 ha per hour and can work 20 hours a day. How many robots match the sprayer's daily capacity, and what margin would you add?
Show solution
- Sprayer daily capacity: about \( 25 \times 10 = 250 \) ha.
- Robot daily capacity: about \( 1.5 \times 20 = 30 \) ha.
- Robots needed: \( 250 / 30 \approx 8.3 \), so 9 robots.
- With 95 per cent availability and the k-out-of-n reasoning of lesson 1, a tenth robot gives margin in a short weather window.
Answer: About nine robots match one sprayer on paper and ten give a margin. The comparison should also include capital cost, compaction, supervision effort and the value of more precise treatment.
Weeding and precision spraying
Weed control is the task where robots have made the clearest commercial progress. Herbicide resistance, consumer demand for reduced chemical use, the cost of hand weeding in organic and vegetable crops, and the arrival of reliable deep-learning plant detection have all pushed in the same direction. Three main approaches exist. Precision spraying uses cameras on a boom to detect weeds and fire individual nozzles only where needed; Deere's See and Spray, which grew out of its 2017 acquisition of Blue River Technology, is the best-known example, and the company reports substantial average herbicide savings compared with broadcast spraying. Mechanical weeding robots use hoes, tines or rotating tools steered by vision to cut weeds between and within crop rows. Thermal and laser weeding robots kill weeds with heat or targeted laser energy; laser weeders have been sold for vegetable crops in North America since the early 2020s.
The core perception problem is detecting and classifying small plants, often at the two- to four-leaf stage, under changing light, with soil, residue and overlapping leaves, at the speed of a moving machine. The robot must also act within milliseconds: at 10 km/h a machine moves 2.8 metres per second, so a nozzle 0.5 m behind the camera has under 0.2 s between detection and spraying. Errors have asymmetric costs: missing a weed leaves competition and seed for future years; killing a crop plant loses yield directly.
Worked problem
Timing a spray decision
A see-and-spray boom moves at 15 km/h. The camera sees 1.0 m ahead of the nozzles. Image capture, inference and valve actuation take 120 ms in total, and the valve must open 20 ms before the nozzle passes the weed. Is there enough time?
Show solution
- Speed: \( 15 / 3.6 = 4.17 \) m/s.
- Time from detection to arrival at the nozzle: \( 1.0 / 4.17 = 0.24 \) s = 240 ms.
- Required: \( 120 + 20 = 140 \) ms, leaving 100 ms of margin.
- At 25 km/h the travel time is 144 ms, just enough; above that the system would miss.
Answer: Yes, with about 100 ms of margin at 15 km/h; the margin disappears near 25 km/h, which sets the maximum operating speed for this layout.
# Herbicide savings and the cost of detection errors (illustrative values)
import numpy as np
rng = np.random.default_rng(4)
area_ha, weed_cover = 100, 0.12           # weeds occupy 12 % of the area on average
broadcast_l_ha, cost_l = 1.5, 12.0         # L/ha and dollars per L
recall, false_pos = 0.95, 0.05             # weeds sprayed, and clean area sprayed by mistake
fields = rng.normal(weed_cover, 0.04, 10).clip(0.02, 0.3)
for wc in fields[:5]:
    sprayed_fraction = recall * wc + false_pos * (1 - wc)
    saving = 1 - sprayed_fraction
    cost_saved = area_ha * broadcast_l_ha * cost_l * saving
print(f"weed cover {wc:5.1%} sprayed {sprayed_fraction:5.1%} herbicide saving {saving:5.1%} ${cost_saved:,.0f} per 100 ha pass")weed cover 9.4% sprayed 13.5% herbicide saving 86.5% $1,558 per 100 ha pass weed cover 11.3% sprayed 15.2% herbicide saving 84.8% $1,527 per 100 ha pass weed cover 18.7% sprayed 21.8% herbicide saving 78.2% $1,408 per 100 ha pass weed cover 14.6% sprayed 18.2% herbicide saving 81.8% $1,473 per 100 ha pass weed cover 5.4% sprayed 9.9% herbicide saving 90.1% $1,622 per 100 ha pass
Savings are largest when weeds are sparse, which is common in fields that are already well managed, and shrink as weed cover rises. Missed weeds (recall below 100 per cent) are the agronomic risk; false positives are mostly a cost. Growers often combine a pre-emergence broadcast application with targeted post-emergence spraying, so real savings depend on the whole programme.
Harvesting, orchards and greenhouses
Robotic harvesting of fresh fruit and vegetables is much harder than weeding. The robot must find fruit hidden among leaves, judge ripeness, plan a reach through branches, detach the fruit without bruising it or damaging the plant, and do so fast enough to compete with skilled pickers. Research and commercial systems for strawberries, apples, tomatoes, sweet peppers and mushrooms have used vacuum tubes, soft grippers and cutting end effectors, and some apple systems use flying or arm-mounted vacuum pickers. Many have struggled with throughput and cost. Orchard and greenhouse growers are adapting crops to robots: trellised two-dimensional fruiting walls, planar canopies and table-top strawberries make fruit far easier to see and reach. Greenhouses also offer controlled lighting, flat floors and rails, so mobile platforms that monitor plants, deleaf tomatoes or move benches are more mature there than in open fields.
| Task | Main robot challenge | Maturity (2026) | Enablers |
|---|---|---|---|
| Auto-steer and autonomous tillage | Obstacle detection and remote supervision | Commercial | RTK, retrofit kits |
| Precision spraying | Plant detection at speed | Commercial | Deep learning, fast valves |
| Mechanical and laser weeding | Within-row precision, throughput | Commercial in specialty crops | Vision guidance, small platforms |
| Fresh fruit harvesting | Occlusion, gentle detachment, speed and cost | Early commercial and pilots | Planar orchards, soft grippers |
| Greenhouse monitoring and handling | Dense plants, narrow aisles | Commercial for some tasks | Rails, controlled light |
| Robotic milking and barn robots | Animal interaction and hygiene | Mature and widespread | Voluntary milking systems, RFID |
Worked problem
Throughput needed for a strawberry harvesting robot
A skilled picker harvests about 25 kg of strawberries per hour. Berries average 18 g. How many seconds per berry must a single-arm robot achieve to match one picker, and what if detachment fails 10 per cent of the time and the robot retries once?
Show solution
- Berries per hour: \( 25000 / 18 \approx 1389 \).
- Time per berry: \( 3600 / 1389 \approx 2.6 \) s.
- With 10 per cent failures and one retry, average attempts per berry are 1.1, so each attempt must take \( 2.6 / 1.1 \approx 2.4 \) s.
Answer: About 2.6 s per berry, or 2.4 s per attempt with retries, which is why many designs use several arms on one platform and work longer hours than a picker.
Livestock and dairy robots
The most widespread farm robots are not in fields but in barns. Voluntary or automatic milking systems let cows choose when to be milked; the robot identifies the cow by RFID, cleans the teats, attaches the cups using cameras or laser sensors, monitors milk quality and records data for each animal. Robotic milking spread from the Netherlands in the 1990s and is now common on dairy farms in Canada and the United States, particularly family farms where labour is scarce. Barn robots also push feed back to the feed bunk, clean manure alleys and feed calves. These systems show a pattern seen across field robotics: success came from redesigning the whole system, including barn layout and cow traffic, rather than replacing a human motion by a robot motion.
Economics, data and policy
Farm robots must pay for themselves within narrow margins and short seasons. The value comes from labour savings, timeliness (getting the work done in the right window), input savings such as herbicide, yield gains from less compaction and more precise treatment, and data. Costs include purchase or subscription, connectivity and correction services, supervision, maintenance and the risk of downtime at critical times. Rural connectivity is a real constraint: RTK corrections, remote supervision and data uploads need cellular or satellite links, and low-earth-orbit satellite internet has improved coverage on many farms since 2021.
In Canada, Agriculture and Agri-Food Canada funds research and adoption programmes for agricultural technology, and provincial agencies and research centres run trials of autonomous equipment; check current programme names and terms, which change between federal funding frameworks. Labour shortages, particularly of seasonal workers who often come through temporary foreign worker streams, are a major driver of interest in horticultural robots.
Data ownership and the right to repair are live policy issues. Autonomous machines collect detailed field, yield and operational data, and farmers want control over who uses it. Repair of modern equipment often requires manufacturer software, and farm groups in both countries have pressed for repair rights; several US states have passed agricultural right-to-repair laws, and Canada amended its Copyright Act in 2024 to allow circumvention of technological protection measures for diagnosis, maintenance and repair. Students designing farm robots should expect customers to ask about these issues.
Common mistakes
MistakeComparing a small robot with a large machine by width alone.
InsteadCompare daily capacity, including operating hours, turns, refills, availability and the number of units in the fleet.
MistakeIgnoring headland turns in job time estimates.
InsteadCount turns and their duration, orient passes along the long side, and split irregular fields into cells.
MistakeQuoting herbicide savings from a clean demonstration field.
InsteadSavings fall as weed density rises; report savings across a range of weed pressures and include detection errors.
MistakeDesigning a harvesting robot to copy a human picker's motion.
InsteadConsider redesigning the crop system, such as planar orchards, and use multiple arms to reach the needed throughput.
MistakeTreating connectivity as given in rural areas.
InsteadPlan for loss of RTK corrections and supervision links, and specify safe behaviour when links drop.
Summary and key terms
- Labour shortages, input costs, compaction and timeliness drive agricultural robotics.
- Autonomy arrives through retrofit kits on large tractors, purpose-built platforms, small-robot fleets and cooperative automation.
- ISO 18497 addresses the safety of highly automated agricultural machines; remote supervision and obstacle detection are standard.
- Boustrophedon coverage time depends on width, overlap, speed, turns and refills, and passes should run along the long side.
- Precision spraying and robotic weeding are commercial, with savings that depend on weed density and detection accuracy.
- Fresh fruit harvesting remains difficult, and crop systems are being redesigned to suit robots.
- Robotic milking is the most widespread farm robot, and data, connectivity and repair rights shape adoption.
- Auto-steer
- GNSS-based steering control that keeps a tractor on planned lines while an operator supervises.
- Retrofit autonomy kit
- Sensors, computing and control interfaces added to an existing machine to allow driverless operation.
- Boustrophedon coverage
- A back-and-forth pattern of parallel passes connected by turns.
- Headland
- The strip at the end of a field used for turning.
- Field efficiency
- Productive working time divided by total time in the field.
- Precision spraying
- Applying herbicide only where weeds are detected, using individually controlled nozzles.
- Controlled traffic farming
- Confining machinery wheels to permanent lanes to limit soil compaction.
- Voluntary milking system
- A robotic system in which cows choose when to be milked.
- Planar orchard
- An orchard trained into a narrow two-dimensional fruiting wall.
- Right to repair
- The ability of owners and independent technicians to diagnose and repair equipment.
Practice problems
Work each problem on paper first, then reveal the answer to check.
A field is 600 m by 300 m and a robot has a 4 m working width with 5 per cent overlap. How many passes are needed along the 600 m side?
Show answer
\( \lceil 300 / 3.8 \rceil = 79 \) passes.
Why do passes along the long side of a field save time?
Show answer
They reduce the number of turns, which are non-productive time.
A robot works at 5 km/h with passes of 500 m and 20 s turns. Find field efficiency, ignoring refills.
Show answer
Pass time \( 500/1.389 = 360 \) s; efficiency \( 360/380 \approx 95 \) per cent.
Name two benefits of fleets of small robots over one large machine.
Show answer
Less soil compaction; redundancy if one fails; lower risk per unit; can work around obstacles and in wet conditions.
Why are herbicide savings from spot spraying smaller in weedy fields?
Show answer
More of the area contains weeds and must be sprayed, so the sprayed fraction rises.
A camera is 0.8 m ahead of the nozzle and total latency is 150 ms. What is the maximum speed?
Show answer
\( 0.8 / 0.15 = 5.3 \) m/s, about 19 km/h.
What makes fresh fruit harvesting harder than weeding?
Show answer
Occlusion, ripeness assessment, gentle detachment without damage, reaching through branches and high throughput at low cost.
How have orchards been changed to suit robots?
Show answer
Planar, trellised fruiting walls make fruit visible and reachable from one side.
Why is robotic milking considered a systems success?
Show answer
It succeeded by redesigning barn layout, cow traffic and management around the robot, not by copying human milking.
Give two policy issues farmers raise about autonomous machinery.
Show answer
Ownership and use of field data; right to repair and access to diagnostic software.
Lesson quiz · 5 questions
Score 60% or more to complete this lesson.
Create a free account to save your progress, take quizzes and earn a certificate.