
ROB-430 · Lesson 11 of 12 · 33 min
Privacy, ethics and social impact
Robots that interact with people are, almost by definition, data-collection machines. To navigate a hospital, a robot maps it, including the people in it. To respond to speech, it listens. To recognize a user, it may store their face. And robots act physically in the world, so their decisions affect safety, livelihoods and dignity in ways that purely digital systems do not. This lesson covers privacy risks and the privacy laws that apply to robots in Canada and the United States, design methods for protecting privacy, frameworks for robot ethics, and the wider social impact of robots on work and society.
How robots affect privacy
Privacy concerns with robots go beyond those of smartphones or websites. Robots move, so their cameras and microphones can reach spaces, such as bedrooms, bathrooms and hospital rooms, that fixed cameras usually do not. They collect data passively and continuously, often about bystanders who never agreed to anything. Their social presence can lead people to disclose more than they would to a form or an app: studies have found that people may share personal information with social robots readily, sometimes without considering where it goes. They can be connected to cloud services and remotely accessed, by manufacturers, employers or attackers. And they create detailed maps of private spaces, which can reveal the layout, contents and routines of a home.
| Data type | Collected for | Privacy risk |
|---|---|---|
| Camera images and video | Navigation, object and person recognition, telepresence | Identification of people, capture of sensitive scenes, use for surveillance |
| Audio | Speech commands, wake words, telepresence | Recording private conversations, voice identification |
| Maps and location | Navigation, cleaning, delivery | Revealing home layout, routines and presence |
| Biometrics (face, voice, gait) | Recognizing authorized users | Highly sensitive; hard to change if leaked |
| Interaction logs | Personalization, performance monitoring | Profiling of behaviour, health or productivity |
| Health and care data | Assistive and care robots | Highly sensitive; subject to health privacy rules |
Workplace robots raise questions of employee monitoring. A collaborative robot logs every cycle, every pause and every intervention, which can be used to measure an individual worker's pace. Used carefully, such data help identify ergonomic problems; used carelessly, they can intensify work and erode trust. Ontario, for example, has required since 2022 that employers with 25 or more employees have a written policy on the electronic monitoring of employees, describing whether and how they monitor and for what purposes. Labour unions and works councils in many countries negotiate limits on how robot data may be used to evaluate workers.
Privacy law in Canada and the United States
In Canada, the Personal Information Protection and Electronic Documents Act, PIPEDA, governs how private-sector organizations collect, use and disclose personal information in the course of commercial activity, except where a province has substantially similar legislation. PIPEDA is built around ten fair information principles, including accountability, identifying purposes, consent, limiting collection, limiting use, disclosure and retention, accuracy, safeguards, openness, individual access and challenging compliance. Quebec, Alberta and British Columbia have their own private-sector privacy laws. Quebec's Law 25, which modernized its privacy legislation in phases between 2022 and 2024, requires a person in charge of protecting personal information, privacy impact assessments for certain projects, privacy-protective default settings, and specific rules for technology that can identify, locate or profile a person: organizations must inform people when such technology is used and, in general, such functions must be off by default. Biometric databases must be disclosed to Quebec's privacy regulator, the Commission d'accès à l'information. Health information is also governed by provincial health privacy laws, such as Ontario's PHIPA. Proposals to replace PIPEDA with a new federal law have been introduced in Parliament in recent years; check the current status. The United States has no comprehensive federal equivalent; it relies on sector-specific laws such as COPPA and on a growing number of state privacy laws.
| Topic | Canada | United States |
|---|---|---|
| General private-sector law | PIPEDA (federal); Quebec, Alberta, BC laws | None federal; state laws such as California's CCPA as amended by the CPRA |
| Identification and location technology | Quebec Law 25: inform people; functions off by default | State laws treat biometrics and precise location as sensitive data |
| Biometrics | Sensitive under PIPEDA guidance; Law 25 disclosure to the CAI | Illinois BIPA: written consent and private right of action |
| Children | Meaningful consent, often parental for young children, under PIPEDA guidance and provincial law | COPPA: verifiable parental consent under 13; FTC rule amended in 2025 |
| Health data | Provincial health privacy laws such as Ontario's PHIPA | HIPAA for covered entities; state health data laws |
| Regulator | Office of the Privacy Commissioner of Canada; provincial commissioners | Federal Trade Commission; state attorneys general and agencies |
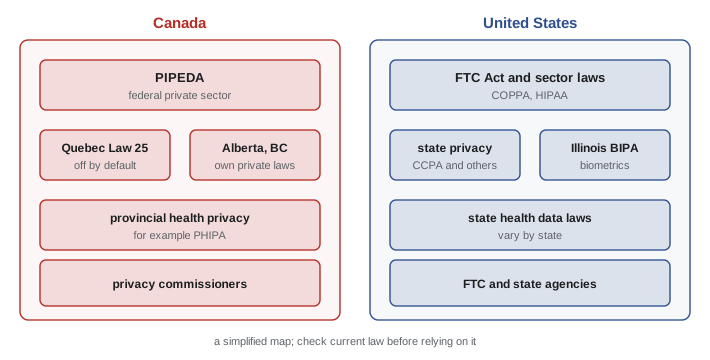
Robots sold across the border must satisfy both sets of rules, and the strictest rule often becomes the design default. Robots marketed in the European Union also face the General Data Protection Regulation and, for certain uses, the EU Artificial Intelligence Act, adopted in 2024, which phases in obligations for high-risk AI systems, including some safety components of machinery, and prohibits some practices outright, such as certain emotion recognition in workplaces and schools.
Privacy by design
Privacy by design, a framework developed by Ann Cavoukian when she was Information and Privacy Commissioner of Ontario, asks designers to build privacy into systems from the start rather than adding it later. Its seven principles include being proactive rather than reactive, privacy as the default setting, privacy embedded into design, full functionality (positive-sum rather than zero-sum), end-to-end security, visibility and transparency, and respect for user privacy. Quebec's Law 25 and the EU's GDPR both include privacy-by-default requirements that echo these principles.
For robots, privacy by design translates into concrete techniques. Process data on the robot rather than sending raw video to the cloud. Keep only what is needed: a navigation map need not keep faces, and a person detector can output positions without storing images. Blur or mask faces and screens in recorded images. Retain logs only as long as needed and delete them automatically. Give users visible indicators when cameras or microphones are active, and physical shutters or switches. Make privacy settings easy to find and protective by default. Secure remote access with strong authentication and encryption, and patch vulnerabilities, since a hacked home robot is a camera on wheels.
Worked problem
How much video would be retained?
A care-home robot records 720p video at 2 megabits per second for 10 hours a day. Compare the storage needed for 90 days of raw video with an approach that stores only event clips of 20 seconds, about 30 times a day.
Show solution
- Raw per day: \( 2 \times 10^6 \times 36\,000 / 8 = 9 \times 10^9 \) bytes, about 9 GB.
- Raw for 90 days: about 810 GB.
- Event clips per day: \( 30 \times 20 = 600 \) s, so \( 2 \times 10^6 \times 600/8 = 150 \) MB.
- Event clips for 90 days: about 13.5 GB, and only if the clips are needed; a 7-day retention cuts it to about 1 GB.
Answer: About 810 GB of raw video versus about 13.5 GB of event clips, a sixtyfold reduction; shorter retention and face blurring reduce risk further.
Statistical privacy techniques can protect aggregated data. A dataset is k-anonymous if every record shares its combination of quasi-identifiers, such as age band, postal code prefix and ward, with at least \( k - 1 \) other records, so that no one can be singled out by those attributes. Differential privacy goes further, adding calibrated random noise to statistics so that the presence or absence of any single person changes the result only slightly. The Laplace mechanism adds noise with scale \( \Delta/\varepsilon \), where \( \Delta \) is how much one person can change the statistic and \( \varepsilon \) is the privacy budget; smaller \( \varepsilon \) means stronger privacy and noisier results.
# k-anonymity check on robot interaction records and a differentially private count
import numpy as np
rng = np.random.default_rng(430)
n = 300
age_band = rng.choice(["18-39", "40-64", "65-79", "80+"], n, p=[0.2, 0.3, 0.3, 0.2])
ward = rng.choice(["A", "B", "C", "D", "E"], n)
postal = rng.choice(["K1A", "K2B", "K2C", "K7L", "M5V"], n, p=[0.3, 0.3, 0.2, 0.15, 0.05])
keys = np.array([f"{a}|{w}|{p}" for a, w, p in zip(age_band, ward, postal)])
_, counts = np.unique(keys, return_counts=True)
print(f"k with age, ward, postal prefix: {counts.min()} (groups of size 1: {np.sum(counts == 1)})")
keys2 = np.array([f"{a}|{w}" for a, w in zip(age_band, ward)])   # drop postal prefix
_, c2 = np.unique(keys2, return_counts=True)
print(f"k after dropping postal prefix: {c2.min()}")
true_count = int(np.sum(age_band == "80+"))
for eps in (0.1, 1.0):
    noisy = true_count + rng.laplace(0, 1 / eps, 5)
print(f"epsilon {eps}: true {true_count}, noisy releases {np.round(noisy).astype(int)}")k with age, ward, postal prefix: 1 (groups of size 1: 19) k after dropping postal prefix: 10 epsilon 0.1: true 67, noisy releases [52 71 68 63 76] epsilon 1.0: true 67, noisy releases [68 66 68 67 68]
Worked problem
Choosing a privacy budget
A hospital wants to publish the number of patients each delivery robot visited per day. One patient can change a count by at most 1. With \( \varepsilon = 0.5 \), what is the Laplace scale, and roughly how large is a typical error? Is it acceptable for counts around 150?
Show solution
- Scale: \( \Delta/\varepsilon = 1/0.5 = 2 \).
- The mean absolute error of Laplace noise equals the scale, about 2 patients.
- Relative to 150, an error of about 2 is roughly 1.3 per cent.
Answer: A scale of 2 and typical errors of about 2 patients, small relative to counts of 150, so \( \varepsilon = 0.5 \) gives useful statistics with meaningful protection; repeated releases consume more of the budget.
Frameworks for robot ethics
Isaac Asimov's Three Laws of Robotics, introduced in his science fiction in the 1940s, are often quoted, but they were written as a plot device that generates dilemmas, and they cannot be implemented: concepts such as harm and obedience are too ambiguous to program, and the laws conflict in practice. Modern robot ethics instead draws on established ethical theories, such as consequentialism, deontology and virtue ethics, and on practical frameworks and standards.
| Framework | Origin | Focus |
|---|---|---|
| Value sensitive design | Batya Friedman and colleagues, from the 1990s | Identifying stakeholders and their values and designing for them throughout |
| BS 8611:2016 | British Standards Institution | Guide to ethical hazards in the design of robots and robotic systems |
| IEEE 7000 series | IEEE Standards Association | Processes and specific topics such as transparency of autonomous systems (IEEE 7001-2021) |
| Privacy by design | Ann Cavoukian, Ontario | Building privacy into systems from the start |
| EU AI Act | European Union, 2024 | Risk-based legal requirements for AI systems, including some robots |
| Principles for AI from many bodies | Governments, OECD, companies | Fairness, accountability, transparency, safety and human oversight |
Several ethical issues recur in HRI. Deception and attachment arise with social robots (lesson 5). Responsibility is unclear when a robot causes harm: is the manufacturer, the programmer, the operator or the owner at fault? Philosophers have described possible responsibility gaps where no one seems fully accountable, which is one reason standards require traceability, logging and clear human oversight. Bias can enter through training data, as when person detectors perform worse for some skin tones or body types, or recognition systems fail for people with disabilities (lesson 10). Robot design can reinforce stereotypes, such as default female voices for assistant robots and male-coded designs for security robots. Autonomy and paternalism must be balanced in assistive robots, which should support users' choices rather than override them. Military and policing uses of robots raise questions of lethal force and accountability that are debated internationally and are beyond the scope of this course.
Social impact: work and society
The effects of robots on employment are debated. Robots substitute for some tasks, complement others and create new ones, such as robot technicians, integrators and fleet supervisors. Economic studies give mixed pictures. A widely cited study by Daron Acemoglu and Pascual Restrepo, published in 2020, estimated that in US local labour markets between 1990 and 2007, each additional industrial robot per thousand workers was associated with a reduction of about 0.2 percentage points in the employment-to-population ratio and about 0.4 per cent in wages. Studies in other countries and periods have found smaller or different effects, sometimes with job losses in manufacturing offset by gains in services. The distribution of effects matters: workers in routine manual jobs, often without post-secondary education, are most exposed, while gains accrue to owners of capital and to skilled workers.
Worked problem
Interpreting an employment estimate
A region has 400,000 working-age people and adds 1.5 robots per thousand workers over a decade. Using an estimate of 0.2 percentage points lower employment-to-population ratio per robot per thousand workers, what change in employment does this imply, and what are the limits of the calculation?
Show solution
- Change in ratio: \( 1.5 \times 0.2 = 0.3 \) percentage points.
- Employment change: \( 0.003 \times 400\,000 = 1200 \) fewer people employed than otherwise.
- Limits: the estimate comes from one country and period, is an average across regions, does not show which jobs are affected, and other factors such as trade and demand change at the same time.
Answer: About 1200 fewer people employed than would otherwise be, as a rough indication only; the effect in a particular region could differ considerably.
HRI design choices influence how robots affect work. Designs that keep workers in skilled, meaningful roles, that remove dangerous or repetitive tasks rather than the most rewarding ones, and that are introduced with training and worker involvement tend to produce better outcomes than designs that simply minimize labour. Governments and unions in Canada and the United States have debated retraining programs, transition support and the taxation of automation; these are policy questions on which reasonable people disagree, but HRI designers should understand that their choices are part of them. Beyond work, robots in public spaces raise questions about who gets to decide where robots operate, how sidewalks and public spaces are shared, and who benefits from the convenience they bring.
An ethics checklist for HRI projects
A short checklist helps bring these issues into everyday design work. Who are all the stakeholders, including bystanders and workers who did not choose the robot? What data does the robot collect, and is each item necessary? Which laws apply in each jurisdiction where the robot will be used? Could the robot deceive, manipulate or create unhealthy dependence? Who is accountable if it causes harm, and can its decisions be reconstructed from logs? Does it work equally well for people of different skin tones, ages, body types, languages and abilities? How will it affect workers' jobs, pace and autonomy? Answering these questions early, documenting the answers and revisiting them as the design evolves is a practical way to act responsibly.
# Privacy configuration for a deployed service robot (listing)
privacy:
  camera:
    on_robot_processing: true
    store_raw_images: false
    face_blur_in_logs: true
    active_indicator_led: true
  microphone:
    wake_word_only: true
    cloud_transcription: opt_in
  maps:
    remove_people_from_saved_maps: true
  logs:
    retention_days: 7
    worker_level_productivity_reports: disabled   # aggregate only, per policy
  remote_access:
    require_mfa: true
    session_recording: true
Common mistakes
MistakeAssuming a robot collects only what its main task needs.
InsteadInventory every sensor and log, including data about bystanders, and minimize each.
MistakeTreating Canadian and US privacy law as equivalent.
InsteadCanada has PIPEDA and provincial laws such as Law 25; the US has sectoral federal laws and state laws.
MistakeIgnoring children's data in a home robot.
InsteadApply COPPA in the US and meaningful, often parental, consent under Canadian law.
MistakeCiting Asimov's laws as a design framework.
InsteadUse value sensitive design, standards such as BS 8611 and IEEE 7001, and applicable law.
MistakeUsing robot logs to rank individual workers without a policy.
InsteadSet and disclose monitoring policies, prefer aggregate data and involve workers.
Summary and key terms
- Mobile, social and connected robots collect sensitive data about users and bystanders.
- Canada regulates private-sector privacy through PIPEDA and provincial laws such as Quebec's Law 25.
- The United States relies on the FTC Act, sectoral laws such as COPPA and HIPAA, and state laws such as the CCPA and Illinois BIPA.
- Privacy by design and data minimization keep raw data on the robot and retain only what is needed.
- k-anonymity and differential privacy protect aggregated data.
- Robot ethics draws on value sensitive design, BS 8611, IEEE 7000 standards and the EU AI Act rather than Asimov's laws.
- Robots affect employment unevenly; design choices influence whether work becomes better or worse.
- PIPEDA
- Canada's federal private-sector privacy law.
- Law 25
- Quebec's 2021 privacy modernization law, phased in from 2022 to 2024.
- COPPA
- US law requiring verifiable parental consent to collect data from children under 13 online.
- BIPA
- Illinois's Biometric Information Privacy Act.
- Privacy by design
- Building privacy protections into systems from the start, by default.
- Data minimization
- Collecting and keeping only the data needed for a stated purpose.
- k-anonymity
- A property in which each record shares its quasi-identifiers with at least k - 1 others.
- Differential privacy
- A guarantee that any one person's data has a limited effect on released statistics.
- Value sensitive design
- A method that accounts for stakeholders' values throughout design.
- Responsibility gap
- A situation where harm occurs but no agent seems fully accountable.
Practice problems
Work each problem on paper first, then reveal the answer to check.
Name two ways robots raise privacy risks beyond fixed cameras.
Show answer
Mobility into private spaces, passive bystander collection, social disclosure, home mapping.
What does Quebec's Law 25 require for technology that can identify, locate or profile a person?
Show answer
Informing people and, in general, keeping such functions off by default.
Which US law covers online data from children under 13?
Show answer
COPPA.
What is notable about Illinois's BIPA?
Show answer
It requires written consent for biometrics and lets individuals sue.
Laplace scale for sensitivity 1 and epsilon 0.2?
Show answer
5.
If every quasi-identifier combination appears at least 4 times, the data are what?
Show answer
4-anonymous.
Give two privacy-by-design techniques for robots.
Show answer
On-robot processing, face blurring, short retention, camera indicators, protective defaults.
Why are Asimov's laws unsuitable as engineering requirements?
Show answer
Their terms are ambiguous and they conflict; they were written as fiction.
Since 2022, which Ontario employers must have an electronic monitoring policy?
Show answer
Employers with 25 or more employees.
Which workers are most exposed to robot substitution?
Show answer
Workers in routine manual jobs.
Lesson quiz · 5 questions
Score 60% or more to complete this lesson.
Create a free account to save your progress, take quizzes and earn a certificate.