
ELV-320 · Lesson 2 of 12 · 22 min
Door operators and door motion
The door operator is the motor and mechanism on the car top that opens and closes the car door, and through the clutch, the hoistway door with it. Priya started Tamsin on operators by putting her on the car top of Tillicum car 1 and then, the same afternoon, on the car top of Quayside car 2. "Same job, sixty years apart," she said. On Tillicum, a DC motor drove a reduction belt and a crank arm, and the door's speed was set by resistors and a set of cam-operated switches that shorted them out at different points of travel. On Quayside, a small permanent-magnet motor drove a toothed belt directly, and a controller read an encoder on the motor and followed a speed profile set in its parameters. Both did the same thing: open the door quickly, slow it down before it hit the stop, close it at a speed the code allows and finish the last few centimeters gently so the door locks without slamming.
What an operator must do
Every door operator has the same jobs, however it is built. It must move the doors through a full cycle, open, hold and close, in a time short enough that the elevator does not lose capacity, but with speed and force limited so that a person struck by the door is not hurt. It must slow the doors before they reach the end of travel in each direction so that panels, hangers and stops are not hammered. It must hold the door fully closed while the car runs, and on most cars hold it fully open while passengers load. It must respond instantly when the reopening device sees an obstruction, reversing the door. And it must tell the controller where the door is: fully open, fully closed and, on modern cars, everywhere in between.
The controller decides when the doors open and close; the operator decides how. On Tillicum, the relays DO and DC from ELV-310 energize the operator's open and close circuits, and limit switches in the operator report door open and door closed. On Quayside, the main controller sends open and close commands to the door controller over a serial link, and the door controller returns the door's position and its own faults. Either way, the door operator is a machine the mechanic adjusts, and it is the source of most door complaints.
Older DC operators with resistors and cams
Tillicum's operator is typical of operators built from the 1950s to the 1980s and still found in many buildings. A small DC motor, often shunt or permanent-magnet, drives a reduction, by belt or gears, to a main shaft. A crank arm on the shaft drives a linkage to the car door hanger, so the door's speed follows the crank's rotation naturally: slow at the start, fastest in the middle and slow near the end, like a piston. Speed is adjusted with resistors: a series resistor in the armature circuit sets the overall speed, and a resistor across the armature, switched by a cam, brakes the motor and slows the door near the ends of travel. The cams are set on the shaft so that their switches operate at the right points. Adjusting such an operator means setting resistor bands and cam positions in a particular order, and the order matters, because each adjustment affects the others.
These operators are reliable and simple but have no feedback. If the door becomes heavier or tighter, because a hoistway door hanger wears or a sill fills with grit, the door simply moves more slowly, or faster if the load lightens. A DC operator that was adjusted to a perfect door on the day it was installed may be quite wrong after twenty years of wear at one landing, which is the floor-3 problem from lesson 1.
# DC door operator: armature voltage and door speed (illustrative)
supply = 110            # operator supply voltage, V DC
r_arm = 6.0            # armature resistance, ohm
k = 0.0138                 # door speed per volt of back-EMF, ft/s per V
current = 1.6           # running current while moving the door, A
for r_series in (10, 20, 30):
    back_emf = supply - current * (r_series + r_arm)
    speed = k * back_emf
print(f"series resistance {r_series:5.1f} ohm -> back-EMF {back_emf:5.1f} V -> door speed about {speed:4.2f} ft/s")series resistance 10.0 ohm -> back-EMF 84.4 V -> door speed about 1.16 ft/s series resistance 20.0 ohm -> back-EMF 68.4 V -> door speed about 0.94 ft/s series resistance 30.0 ohm -> back-EMF 52.4 V -> door speed about 0.72 ft/s
More series resistance drops more voltage, leaves less back-EMF across the motor, and slows the door. The numbers are illustrative, but the pattern is what Ray uses when he sets a band on an old operator: move the band a little, time the door, and move it again.
Modern closed-loop operators
Most operators installed in the last twenty-five years are closed-loop: an AC or permanent-magnet motor is run by its own small variable-frequency drive or motor controller, with an encoder or position sensor on the motor or the belt. The door controller follows a programmed speed profile for opening and closing, measures the actual position and speed and corrects the motor current to stay on the profile. Because it measures the load, it can compensate for a heavier or stiffer door, detect when the door is obstructed by the rise in current or loss of speed, learn the length of travel automatically and limit the force and kinetic energy within set bounds. Quayside's operator learns its door width on a learn run, stores separate profiles for the car door alone and for each landing, and logs faults such as door obstructed, door slow to close and encoder fault.
Some operators use a motor directly on a toothed belt that carries the door hangers; others use a gearmotor with arms; a few use linear motors. Whatever the mechanism, the parameters typically include opening speed, closing speed, acceleration, the length of the slow zones at each end, the force limit on closing, the hold force while open and closed, and the nudging speed used when the doors have been held open too long. The maker's manual gives the allowed ranges, and the kinetic energy and force limits of lesson 5 set the outer bounds.
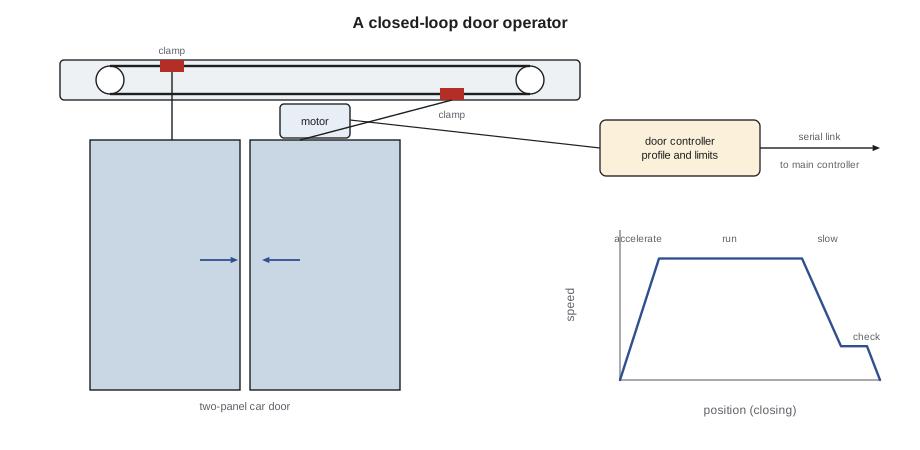
The door motion profile
A good door cycle has a recognizable shape. On opening, the door starts slowly while the clutch engages and the interlock releases, accelerates to opening speed, runs, then slows down over the last part of travel and stops against its open stop without a bump. It holds open for the dwell time set by the controller. On closing, it accelerates to closing speed, which is slower than opening speed because closing is when people are struck, runs, slows over the last part of travel, creeps through a short check zone where the clutch releases and the hoistway door picks up its lock, and closes fully with enough force to make the door contacts and interlock reliably. If the door reverses on an obstruction, it stops and reopens at once.
# Opening and closing times for a trapezoidal door profile
width = 1.8              # door travel for the opening, ft
v_open, v_close = 2.0, 1.0     # top speeds, ft/s
a = 4.0                  # acceleration and deceleration, ft/s2
slow = 0.16               # length of the slow zone at the end of travel, ft
v_slow = 0.26            # creep speed in the slow zone, ft/s

def cycle_time(v):
    d_acc = v * v / (2 * a)            # distance to accelerate (and to decelerate)
    run = width - slow - 2 * d_acc     # distance at top speed
    return 2 * v / a + run / v + slow / v_slow

print(f"opening time {cycle_time(v_open):.1f} s, closing time {cycle_time(v_close):.1f} s")opening time 1.9 s, closing time 2.5 s
These are the figures for one panel of Quayside's 42 in center-opening door, each panel traveling half the opening. The closing time is longer than the opening time because the closing speed is half the opening speed, and both times include the slow zone at the end. A door that opens in under two seconds and closes in about three is typical for a busy passenger car; the closing time must never be shorter than the minimum on the door's data plate, which comes from the kinetic energy limits.
Dwell time, nudging and accessibility
How long the doors stay open is set by the controller, not the operator, but mechanics adjust it. Most controllers use a longer dwell when a car stops for a hall call, so that a waiting passenger has time to see the lantern and reach the car, and a shorter dwell for a car call, when passengers are already inside. Accessibility rules set minimums for both. In the US, the 2010 ADA Standards set a minimum time from the hall lantern signal to the doors starting to close that grows with the walking distance from the call button to the car, with a floor of a few seconds, and a minimum door dwell for a car call. The controller's dwell parameters must meet these, and many buildings choose longer times than the minimum.
If the doors are held open, by a passenger blocking the light curtain or a cart in the entrance, many controllers start nudging after a set time: a buzzer sounds and the doors close at reduced speed with the light curtain bypassed, relying on a mechanical edge or force limit. The code allows nudging only at a lower kinetic energy than normal closing, the figure for a door without an operative reopening device, which lesson 5 gives. Nudging keeps a car from being held out of service by one blocked door, but it must be set gently and never on doors whose only protection is the light curtain.
# Hall call notification time: minimum time from lantern to doors closing
# T = distance / walking speed, with a minimum (accessibility rule, illustrative form)
walk_speed = 1.5            # ft/s
minimum = 5.0                # s
for name, d in [("button beside the car", 5.0), ("button at end of lobby", 10.0), ("across a wide lobby", 20.0)]:
    t = max(minimum, d / walk_speed)
print(f"{name:<24} distance {d:4.1f} ft -> at least {t:4.1f} s")button beside the car distance 5.0 ft -> at least 5.0 s button at end of lobby distance 10.0 ft -> at least 6.7 s across a wide lobby distance 20.0 ft -> at least 13.3 s
The walking speed in the formula is slow on purpose, so that a person using a cane or a wheelchair can reach the car. At Quayside, with destination dispatch, the indicated car can be at the far end of the lobby, and its dwell parameters were set from the longest walk, not the shortest.
Clutches, vanes and how the car door drives the hoistway door
The car door must pick up the hoistway door at every floor. The device that does it is the clutch, also called the door coupler or vane. On many cars it is a pair of vanes on the car door that close together, or expand apart, at the start of the opening stroke to grip two rollers on the hoistway door's interlock. As the vanes grip, they first lift or push the interlock roller to unlock the hoistway door, then drag it open with the car door. On closing, the car door pushes the hoistway door closed, and in the last part of travel the vanes release the rollers; the hoistway door's closer finishes the job and the interlock locks. The clutch is also what makes the car door restrictor and the interlock's unlocking zone work, as lesson 4 explains. A clutch that is out of alignment with the hoistway door rollers by a few millimeters at one floor causes noisy, jerky or failed door operation at that floor only.
Worked problem
A door that reverses for no reason
Quayside car 3's door controller logs "door obstructed" several times a day on closing, but only at floor 14, and passengers say the door reopens with nothing in the way. What is the likely cause and how should Priya and Tamsin find it?
Show solution
- A closed-loop operator detects obstruction from current and speed. If the floor 14 hoistway door is stiffer than the profile expects, the operator sees a load it reads as an obstruction.
- Check the floor 14 hoistway door by hand with the car away and the hoistway protected: hangers, rollers, track, sill guide, closer and the interlock roller.
- Check the alignment of the car door clutch with the floor 14 rollers; a roller struck late or dragged makes a load spike at the same point every time.
- Correct the hoistway door, then let the operator relearn that landing if the maker requires it, and confirm the faults stop.
Answer: Most likely a dragging floor 14 hoistway door or misaligned clutch rollers, found and fixed at that landing rather than by lowering the operator's obstruction sensitivity.
Common mistakes
MistakeRaising the closing speed to cure a slow door.
InsteadFind why the door is slow, usually drag or a tight hoistway door; closing speed is limited by kinetic energy.
MistakeMaking the closing time shorter than the data plate minimum.
InsteadThe data plate time is the floor; the door must never close faster.
MistakeLowering a closed-loop operator's obstruction sensitivity to stop nuisance reversals.
InsteadFix the drag or misalignment that the operator is correctly detecting.
MistakeAdjusting one resistor band on an old DC operator without rechecking the others.
InsteadFollow the maker's order and re-time the whole cycle after each change.
MistakeSetting nudging on a door whose only reopening protection is a light curtain.
InsteadNudging bypasses the light curtain, so it needs another means, such as a force limit or mechanical edge.
Summary and key terms
- The door operator opens and closes the car door, and through the clutch, the hoistway door.
- Older DC operators set speed with resistors and cams and have no feedback, so wear changes their behavior.
- Closed-loop operators follow a speed profile with encoder feedback, compensate for load, detect obstruction and limit force and energy.
- A good cycle accelerates, runs, slows, checks and closes gently; closing is slower than opening.
- Dwell times and nudging are controller settings bounded by accessibility rules and the code's energy limits.
- Clutch alignment with each landing's hoistway door rollers is a common cause of floor-specific door problems.
- Door operator
- The motor and mechanism on the car that opens and closes the doors.
- Closed-loop operator
- An operator that measures door position and speed and corrects the motor to follow a programmed profile.
- Clutch (vane)
- The device on the car door that engages the hoistway door rollers, unlocks the interlock and drags the hoistway door.
- Dwell time
- How long the doors remain fully open before closing.
- Nudging
- Closing the doors at reduced speed and energy, with a buzzer, after they have been held open too long.
- Check zone
- The short creep zone at the end of closing where the clutch releases and the interlock locks.
Practice problems
Work each problem on paper first, then reveal the answer to check.
Why is closing speed lower than opening speed?
Show answer
Closing is when passengers are struck, so its speed and energy are limited.
What happens to an old DC operator's door speed if a hoistway door becomes stiffer?
Show answer
The door slows, because the operator has no feedback to compensate.
What does a closed-loop operator use to detect an obstruction?
Show answer
A rise in motor current or a loss of speed compared with its profile.
When may doors nudge, and at what energy?
Show answer
After being held open for a set time, at the reduced energy the code allows for a door without an operative reopening device, with a warning buzzer.
A door is noisy at one floor only. Name two things to check at that landing.
Show answer
Any two of: clutch alignment with the rollers, hoistway door hangers and track, sill guide, closer, interlock roller.
Lesson quiz · 5 questions
Score 60% or more to complete this lesson.
Create a free account to save your progress, take quizzes and earn a certificate.